ICCK

Hui Zhou

NanJing XiaoZhuang University

Section 01

Academic Profile

No academic profile information available at the moment.

Section 02

Editorial Roles

This user currently does not serve as an editor for any ICCK journals.

Section 03

ICCK Publications

Free Access | Review Article | 16 September 2026
Advances in ROS-Based Robot Simulation Technology: A Mini Review
ICCK Transactions on Intelligent Cyber-Physical Systems | Volume 1, Issue 3: 93-96, 2026 | DOI: 10.62762/TICPS.2026.304297
Abstract
Robot simulation provides a repeatable and risk-controlled environment for developing increasingly integrated robotic systems. Within this field, the Robot Operating System (ROS) links robot models, sensors, controllers, and algorithms through modular communication interfaces and has formed a broad ecosystem with simulators such as Gazebo, Webots, and NVIDIA Isaac Sim. Recent progress has shifted from basic rigid-body and sensor simulation toward ROS~2-based interface unification, high-fidelity perception, GPU-accelerated synthetic-data generation, and Sim-to-Real transfer. This paper reviews these advances, discusses key developments in modeling, navigation, manipulation, and sensor simulat... More >

Graphical Abstract
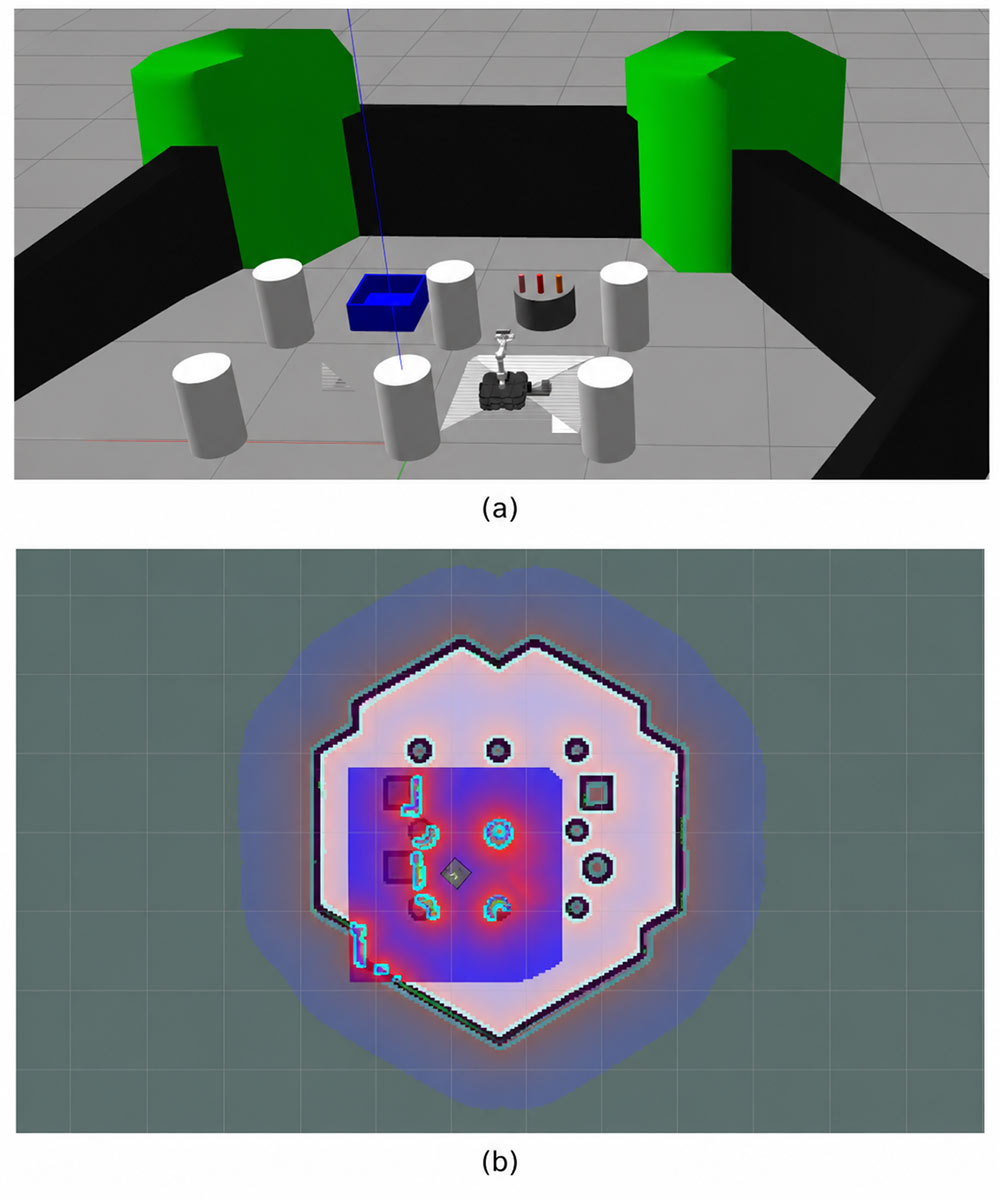
Advances in ROS-Based Robot Simulation Technology: A Mini Review
Free Access | Research Article | 19 February 2026 | Cited: 1
Design and Kinematic Simulation Analysis of a Vision-Guided 5-DOF Robotic Arm System
ICCK Transactions on Intelligent Cyber-Physical Systems | Volume 1, Issue 1: 51-59, 2026 | DOI: 10.62762/TICPS.2026.895157
Abstract
Traditional teach-and-repeat robotic arms, which rely on pre-programmed trajectories and manual teaching, struggle to adapt to operational requirements in unstructured environments where the position, posture, or type of target objects may vary unpredictably. In contrast, robot control technology based on visual servoing empowers robotic arms with "visual perception" capabilities, enabling real-time environment sensing and dynamic action adjustment, which significantly enhances the flexibility and efficiency of sorting and assembly operations. This paper designs and implements a five-degree-of-freedom (5-DOF) vision-guided picking robotic arm system based on a distributed control architectur... More >

Graphical Abstract
Design and Kinematic Simulation Analysis of a Vision-Guided 5-DOF Robotic Arm System