
ICCK Transactions on Sensing, Communication, and Control | Volume 3, Issue 4: 210-236, 2026 | DOI: 10.62762/TSCC.2026.637136
Abstract
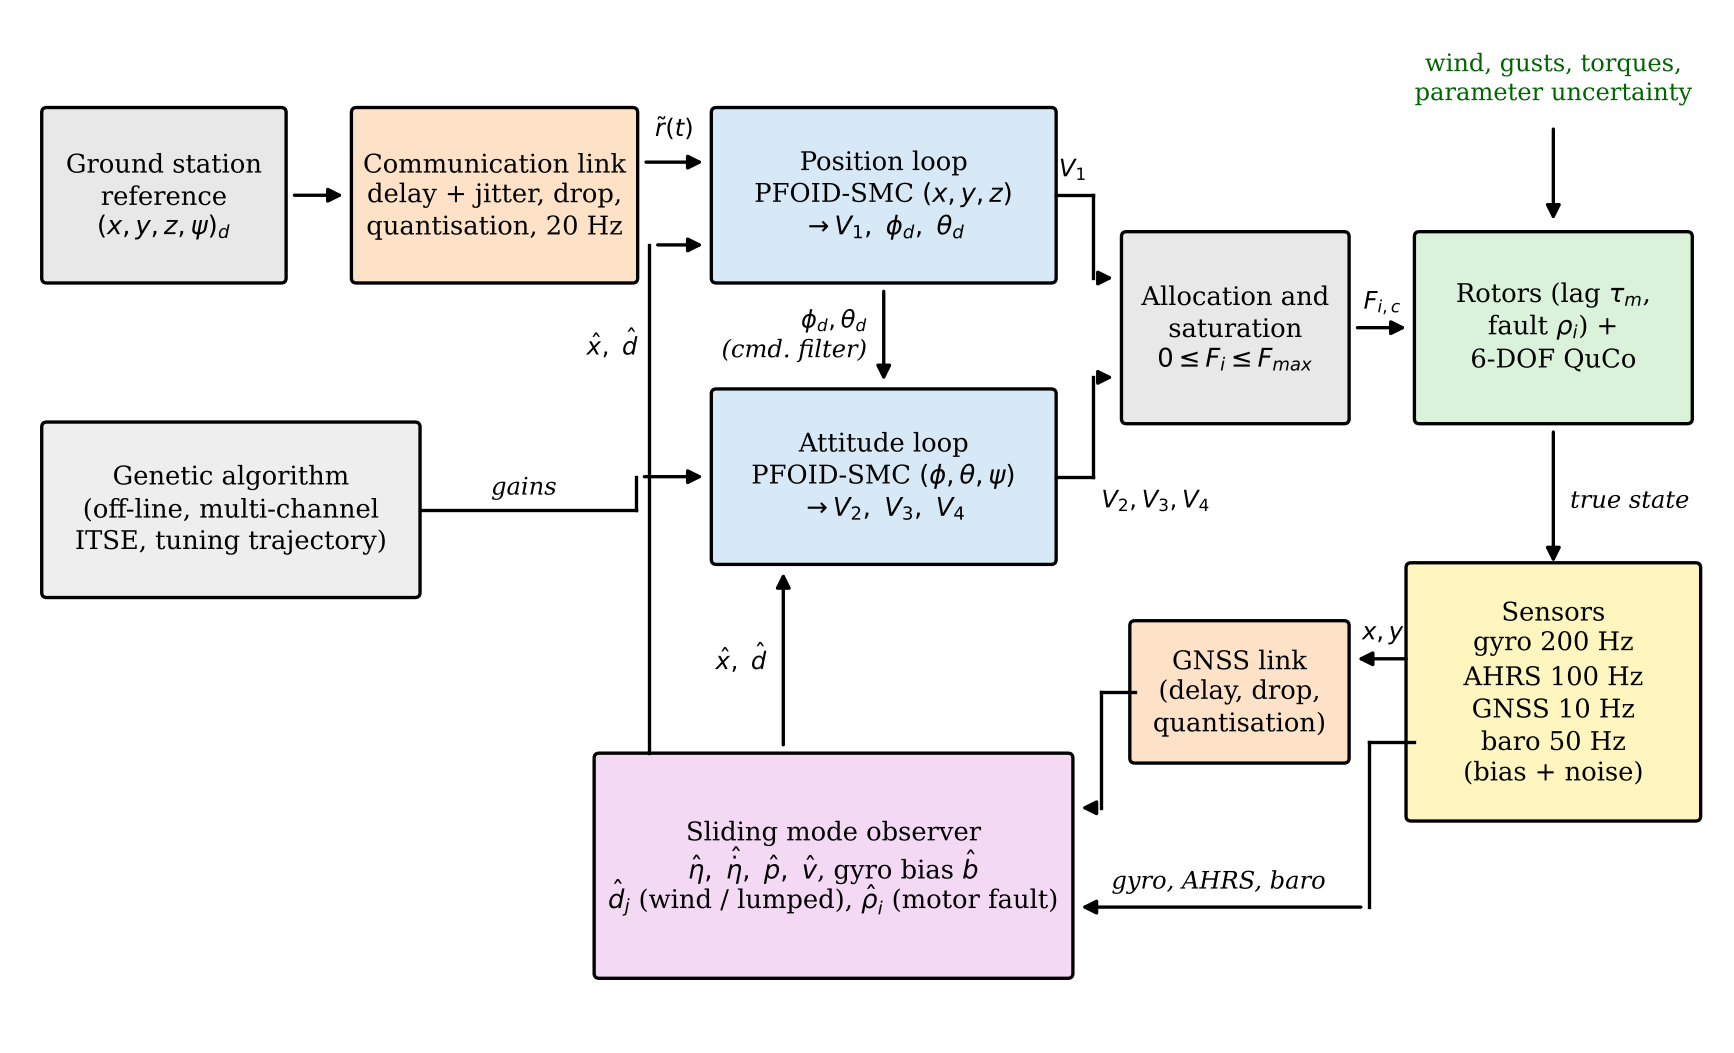
This paper presents a genetic algorithm (GA)-tuned sliding mode controller for a quadcopter (QuCo) in which the sliding surface is built from a proportional-fractional-order-integral-derivative (PFOID) error function (PFOID-SMC). The aim is to achieve accurate trajectory tracking in the presence of aerodynamic drag, wind, sensor noise and parametric uncertainty. Sensing and communication are kept inside the closed loop. The controller receives only measured or estimated states from a gyroscope (200~Hz), an attitude and heading reference system (100~Hz), an RTK-GNSS receiver (10~Hz) and a barometer (50~Hz), each with its own bias and noise, while the reference and the GNSS position are sent o... More >
Graphical Abstract