
Chinese Journal of Information Fusion | Volume 3, Issue 3: 209-225, 2026 | DOI: 10.62762/CJIF.2026.632794
Abstract
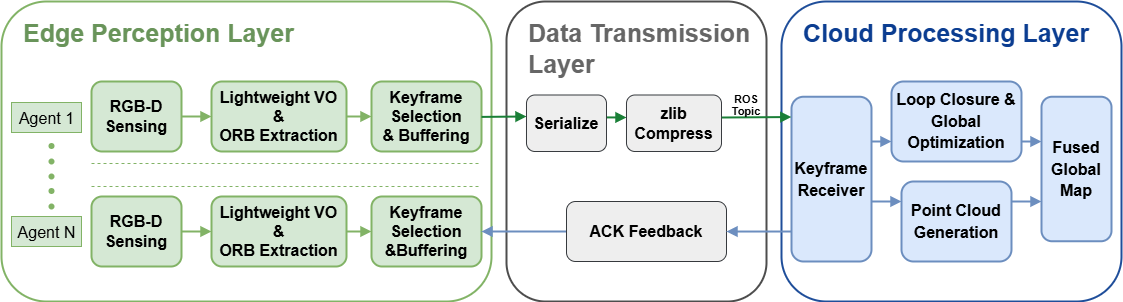
To alleviate the computational and memory pressure faced by resource-constrained edge platforms in large-scale homogeneous multi-agent visual SLAM tasks, this paper designs and validates a centralized homogeneous multi-agent visual SLAM system based on a cloud-native architecture. The system adopts a cloud-edge functional decoupling strategy: real-time perception modules, such as visual odometry, keyframe extraction, and local tracking, are retained on the edge side, while computationally intensive tasks, including loop-closure detection, pose graph optimization, global map management, and multi-source map fusion, are centrally executed in the cloud. To accommodate bandwidth fluctuations, tr... More >
Graphical Abstract