by


ICCK Transactions on Intelligent Cyber-Physical Systems | Volume 1, Issue 3: 113-120, 2026 | DOI: 10.62762/TICPS.2026.133355
Abstract
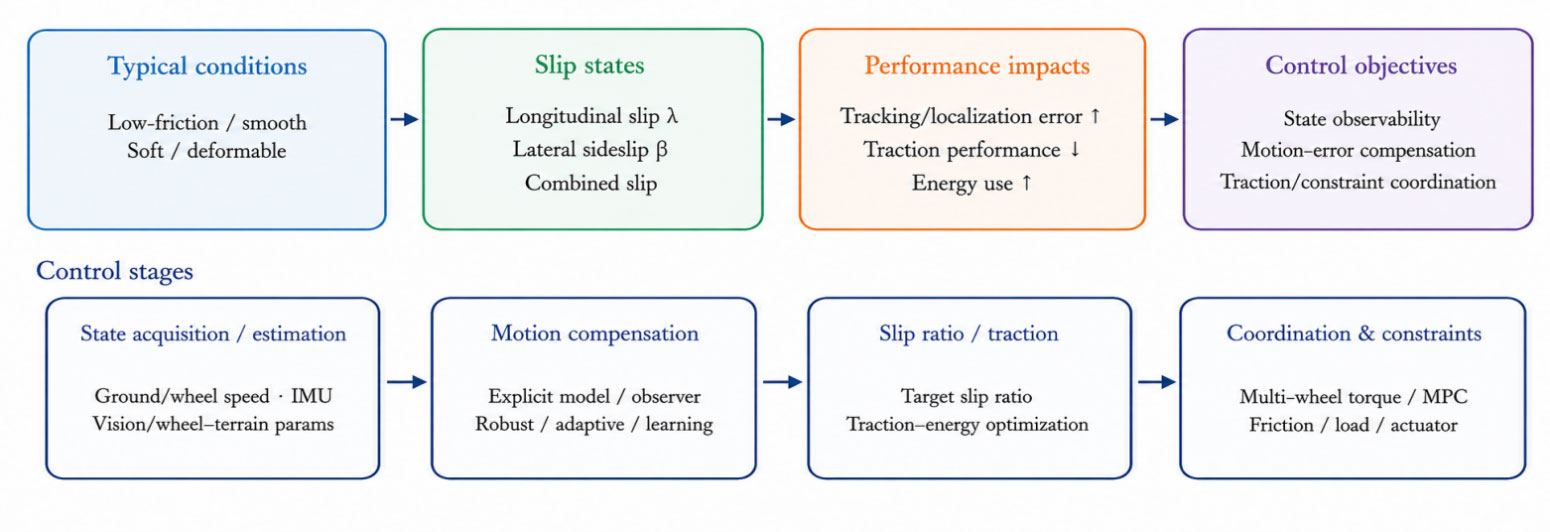
Wheeled mobile robots are prone to longitudinal slip, lateral sideslip, and combined slip when operating on wet, soft, and unstructured terrain, which degrades localization accuracy, trajectory tracking, traction performance, and energy consumption. Based on 36 studies, this paper reviews slip modeling and state estimation, trajectory compensation, slip-ratio and traction control, multi-wheel slip coordination and torque allocation, and integrated multi-constraint control. The methods are compared in terms of technological evolution, control objectives, applicable operating conditions, validation levels, and representative experimental results. Existing studies still face challenges in model... More >
Graphical Abstract