by


ICCK Transactions on Intelligent Cyber-Physical Systems | Volume 1, Issue 3: 104-112, 2026 | DOI: 10.62762/TICPS.2026.513798
Abstract
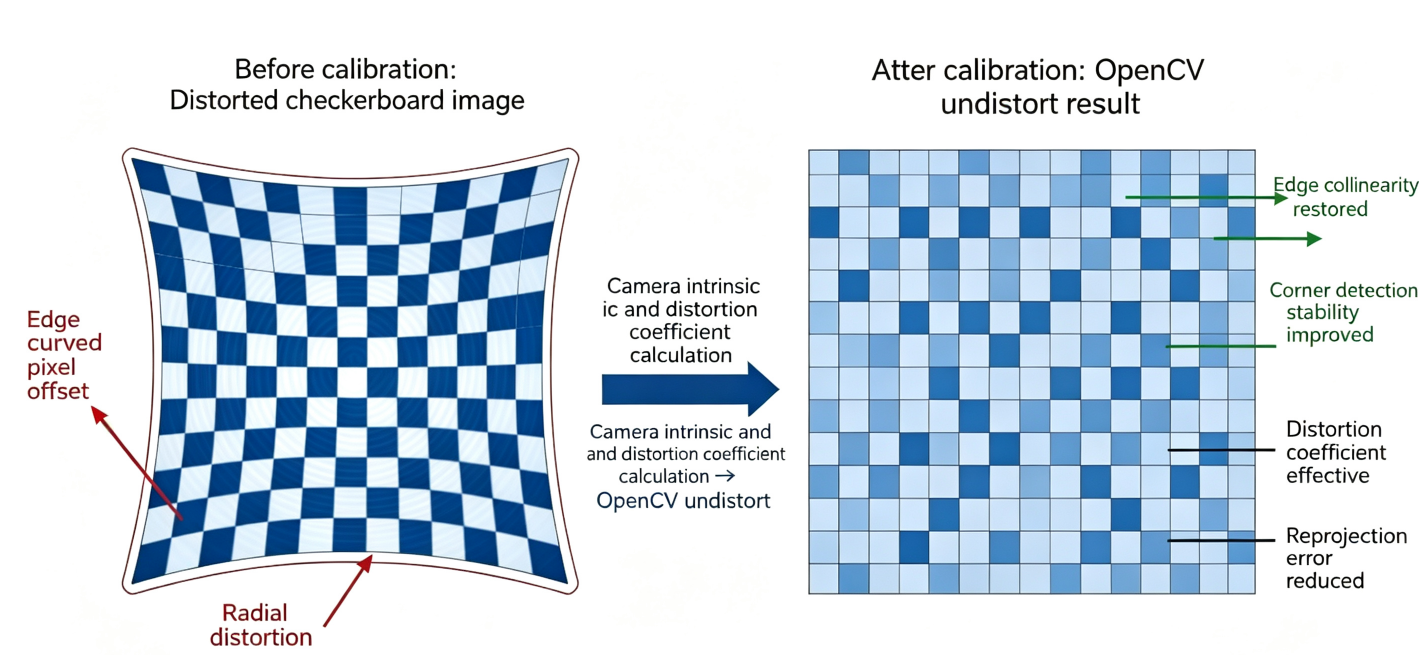
This paper reviews the OpenCV-based vision system for robotic-arm grasping across three core modules-camera calibration, image preprocessing and recognition, and binocular 3D reconstruction-together with lightweight deployment on embedded platforms. Using the calib3d module, monocular, binocular, and hand-eye calibration procedures are described, which correct lens distortion and unify coordinate frames and thereby address grasping-positioning errors. Image processing algorithms, including grayscale transformation, Gaussian and median filtering, Otsu segmentation, and feature matching, are compared for static and dynamic assembly-line scenarios. Binocular stereo matching generates disparity... More >
Graphical Abstract