

A Review of Research and Applications of OpenCV in Robotic Arm Grasping Vision Systems

Article Information
Abstract
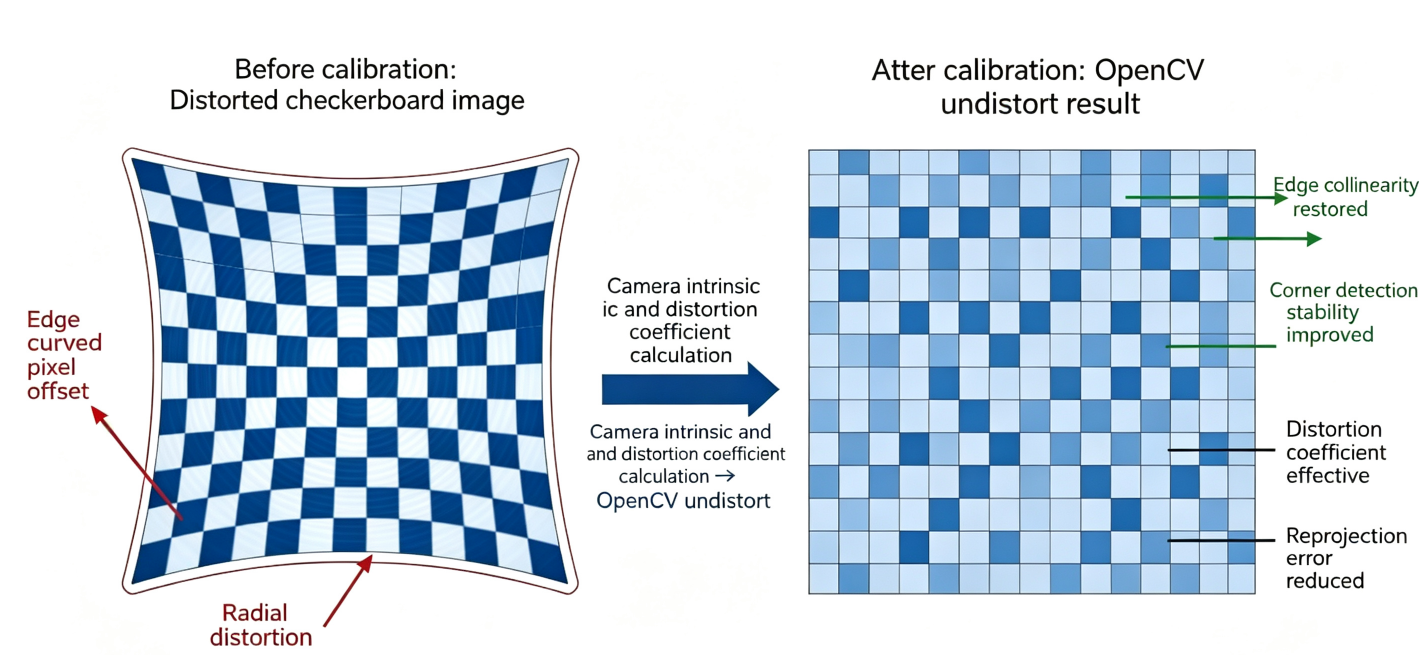
This paper reviews the OpenCV-based vision system for robotic-arm grasping across three core modules-camera calibration, image preprocessing and recognition, and binocular 3D reconstruction-together with lightweight deployment on embedded platforms. Using the calib3d module, monocular, binocular, and hand-eye calibration procedures are described, which correct lens distortion and unify coordinate frames and thereby address grasping-positioning errors. Image processing algorithms, including grayscale transformation, Gaussian and median filtering, Otsu segmentation, and feature matching, are compared for static and dynamic assembly-line scenarios. Binocular stereo matching generates disparity maps for depth recovery and 6-DoF pose estimation, supporting peg-in-hole assembly and obstacle avoidance. For embedded platforms (Raspberry Pi, TQ210, and STM32-based systems), optimization strategies such as library pruning and reduced image resolution or disparity search range are summarized to improve real-time performance. The review indicates that OpenCV-based solutions are open-source, low-cost, and portable, and are suitable for conventional grasping tasks; however, their robustness remains limited under strong illumination and occlusion. Integrating deep learning, multi-sensor fusion, and online hand--eye calibration are suggested to extend their applicability to complex environments.
Graphical Abstract
Keywords
Data Availability Statement
Funding
Conflicts of Interest
AI Use Statement
Ethical Approval and Consent to Participate
References
- Bradski, G., & Kaehler, A. (2008). Learning OpenCV: Computer Vision with the OpenCV Library. Sebastopol, CA, USA: O'Reilly Media. ISBN 978-0-596-51613-0. https://books.google.com/books?id=seAgiOfu2EIC
[Google Scholar] - Pulli, K., Baksheev, A., Kornyakov, K., & Eruhimov, V. (2012). Real-time computer vision with OpenCV. Communications of the ACM, 55(6), 61-69.
[CrossRef] [Google Scholar] - Kaymak, C., & Uçar, A. (2018). Implementation of object detection and recognition algorithms on a robotic arm platform using Raspberry Pi. In 2018 International Conference on Artificial Intelligence and Data Processing (IDAP). IEEE.
[CrossRef] [Google Scholar] - Zhang, Z. (2000). A flexible new technique for camera calibration. IEEE Transactions on pattern analysis and machine intelligence, 22(11), 1330-1334.
[CrossRef] [Google Scholar] - Abdullah-Al-Noman, M., Eva, A. N., Yeahyea, T. B., & Khan, R. (2022). Computer vision-based robotic arm for object color, shape, and size detection. Journal of Robotics and Control (JRC), 3(2), 180-186.
[CrossRef] [Google Scholar] - Titu, M. F. S., Haque, S. R., Islam, R., Hossain, A., Qayum, M. A., & Khan, R. (2024). Experiments with cooperative robots that can detect object's shape, color and size to perform tasks in industrial workplaces. International journal of intelligent robotics and applications, 8(1), 179-192.
[CrossRef] [Google Scholar] - Jain, T., Mushtaq, F., Ramesh, K., Deshmukh, S., Ray, T., Parimi, C., ... & Jha, P. K. (2023). Development of machine vision approach for mechanical component identification based on its dimension and pitch. arXiv preprint arXiv:2310.01995.
[CrossRef] [Google Scholar] - Wang, Z., Li, P., Zhang, H., Zhang, Q., Ye, C., Han, W., & Tian, W. (2023). A binocular vision method for precise hole recognition in satellite assembly systems. Measurement, 221, 113455.
[CrossRef] [Google Scholar] - Wang, X., Yang, C., Ju, Z., Ma, H., & Fu, M. (2017). Robot manipulator self-identification for surrounding obstacle detection. Multimedia Tools and Applications, 76(5), 6495-6520.
[CrossRef] [Google Scholar] - Le, T.-T., Le, Q.-D., Chen, Y.-R., Vidal, J., & Lin, C.-Y. (2021). 6D pose estimation with combined deep learning and 3D vision techniques for a fast and accurate object grasping. Robotics and Autonomous Systems, 141, 103775.
[CrossRef] [Google Scholar] - Liang, J., Zhang, J., Pan, B., Xu, S., Zhao, G., Yu, G., & Zhang, X. (2021). Visual reconstruction and localization-based robust robotic 6-DoF grasping in the wild. IEEE Access, 9, 72451-72464.
[CrossRef] [Google Scholar] - Tsai, R. Y., & Lenz, R. K. (1989). A new technique for fully autonomous and efficient 3 d robotics hand/eye calibration. IEEE Transactions on robotics and automation, 5(3), 345-358.
[CrossRef] [Google Scholar] - Hirschmüller, H. (2008). Stereo processing by semiglobal matching and mutual information. IEEE Transactions on Pattern Analysis and Machine Intelligence, 30(2), 328-341.
[CrossRef] [Google Scholar] - Vo, C. D., Dang, D. A., & Le, P. H. (2022). Development of multi-robotic arm system for sorting system using computer vision. Journal of Robotics and Control (JRC), 3(5), 690-698.
[CrossRef] [Google Scholar] - Otsu, N. (1979). A threshold selection method from gray-level histograms. IEEE Transactions on Systems, Man, and Cybernetics, 9(1), 62-66.
[CrossRef] [Google Scholar] - Lowe, D. G. (2004). Distinctive image features from scale-invariant keypoints. International journal of computer vision, 60(2), 91-110.
[CrossRef] [Google Scholar] - Bradski, G. R. (1998). Computer vision face tracking for use in a perceptual user interface. Intel Technology Journal, 2nd Quarter.
[Google Scholar] - Allen, P. K., Timcenko, A., Yoshimi, B., & Michelman, P. (1993). Automated tracking and grasping of a moving object with a robotic hand-eye system. IEEE Transactions on Robotics and Automation, 9(2), 152-165.
[CrossRef] [Google Scholar]
Cite This Article
TY  - JOUR
AU  - Du, Rui
PY  - 2026
DA  - 2026/09/24
TI  - A Review of Research and Applications of OpenCV in Robotic Arm Grasping Vision Systems
JO  - ICCK Transactions on Intelligent Cyber-Physical Systems
T2  - ICCK Transactions on Intelligent Cyber-Physical Systems
JF  - ICCK Transactions on Intelligent Cyber-Physical Systems
VL  - 1
IS  - 3
SP  - 104
EP  - 112
DO  - 10.62762/TICPS.2026.513798
UR  - https://www.icck.org/article/abs/TICPS.2026.513798
KW  - OpenCV
KW  - robotic arm
KW  - machine vision
KW  - camera calibration
KW  - lightweight embedded deployment
AB  - This paper reviews the OpenCV-based vision system for robotic-arm grasping across three core modules-camera calibration, image preprocessing and recognition, and binocular 3D reconstruction-together with lightweight deployment on embedded platforms. Using the calib3d module, monocular, binocular, and hand-eye calibration procedures are described, which correct lens distortion and unify coordinate frames and thereby address grasping-positioning errors. Image processing algorithms, including grayscale transformation, Gaussian and median filtering, Otsu segmentation, and feature matching, are compared for static and dynamic assembly-line scenarios. Binocular stereo matching generates disparity maps for depth recovery and 6-DoF pose estimation, supporting peg-in-hole assembly and obstacle avoidance. For embedded platforms (Raspberry Pi, TQ210, and STM32-based systems), optimization strategies such as library pruning and reduced image resolution or disparity search range are summarized to improve real-time performance. The review indicates that OpenCV-based solutions are open-source, low-cost, and portable, and are suitable for conventional grasping tasks; however, their robustness remains limited under strong illumination and occlusion. Integrating deep learning, multi-sensor fusion, and online hand--eye calibration are suggested to extend their applicability to complex environments.
SN  - 3071-2947
PB  - Institute of Central Computation and Knowledge
LA  - English
ER  -
@article{Du2026A,
  author = {Rui Du},
  title = {A Review of Research and Applications of OpenCV in Robotic Arm Grasping Vision Systems},
  journal = {ICCK Transactions on Intelligent Cyber-Physical Systems},
  year = {2026},
  volume = {1},
  number = {3},
  pages = {104-112},
  doi = {10.62762/TICPS.2026.513798},
  url = {https://www.icck.org/article/abs/TICPS.2026.513798},
  abstract = {This paper reviews the OpenCV-based vision system for robotic-arm grasping across three core modules-camera calibration, image preprocessing and recognition, and binocular 3D reconstruction-together with lightweight deployment on embedded platforms. Using the calib3d module, monocular, binocular, and hand-eye calibration procedures are described, which correct lens distortion and unify coordinate frames and thereby address grasping-positioning errors. Image processing algorithms, including grayscale transformation, Gaussian and median filtering, Otsu segmentation, and feature matching, are compared for static and dynamic assembly-line scenarios. Binocular stereo matching generates disparity maps for depth recovery and 6-DoF pose estimation, supporting peg-in-hole assembly and obstacle avoidance. For embedded platforms (Raspberry Pi, TQ210, and STM32-based systems), optimization strategies such as library pruning and reduced image resolution or disparity search range are summarized to improve real-time performance. The review indicates that OpenCV-based solutions are open-source, low-cost, and portable, and are suitable for conventional grasping tasks; however, their robustness remains limited under strong illumination and occlusion. Integrating deep learning, multi-sensor fusion, and online hand--eye calibration are suggested to extend their applicability to complex environments.},
  keywords = {OpenCV, robotic arm, machine vision, camera calibration, lightweight embedded deployment},
  issn = {3071-2947},
  publisher = {Institute of Central Computation and Knowledge}
}
Article Metrics
Publisher's Note
ICCK stays neutral with regard to jurisdictional claims in published maps and institutional affiliations.
Rights and Permissions
Portico
