Volume 1, Issue 3 (In Progress)


In Progress
Citations: Crossref logo 0,   0   |   Viewed: 2012, Download: 777

Table of Contents

Free Access | Review Article | 25 September 2026
A Review of Wheel-Slip Control Algorithms for Wheeled Mobile Robots
ICCK Transactions on Intelligent Cyber-Physical Systems | Volume 1, Issue 3: 113-120, 2026 | DOI: 10.62762/TICPS.2026.133355
Abstract
Wheeled mobile robots are prone to longitudinal slip, lateral sideslip, and combined slip when operating on wet, soft, and unstructured terrain, which degrades localization accuracy, trajectory tracking, traction performance, and energy consumption. Based on 36 studies, this paper reviews slip modeling and state estimation, trajectory compensation, slip-ratio and traction control, multi-wheel slip coordination and torque allocation, and integrated multi-constraint control. The methods are compared in terms of technological evolution, control objectives, applicable operating conditions, validation levels, and representative experimental results. Existing studies still face challenges in model... More >

Graphical Abstract
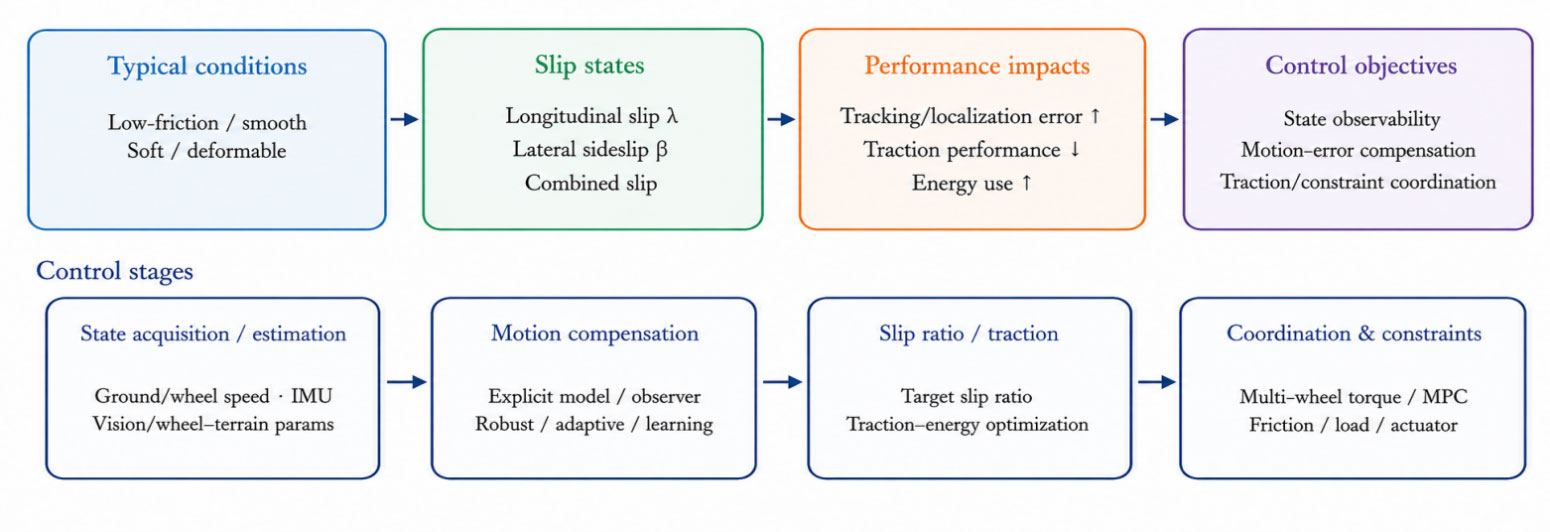
A Review of Wheel-Slip Control Algorithms for Wheeled Mobile Robots
Free Access | Review Article | 24 September 2026
A Review of Research and Applications of OpenCV in Robotic Arm Grasping Vision Systems
ICCK Transactions on Intelligent Cyber-Physical Systems | Volume 1, Issue 3: 104-112, 2026 | DOI: 10.62762/TICPS.2026.513798
Abstract
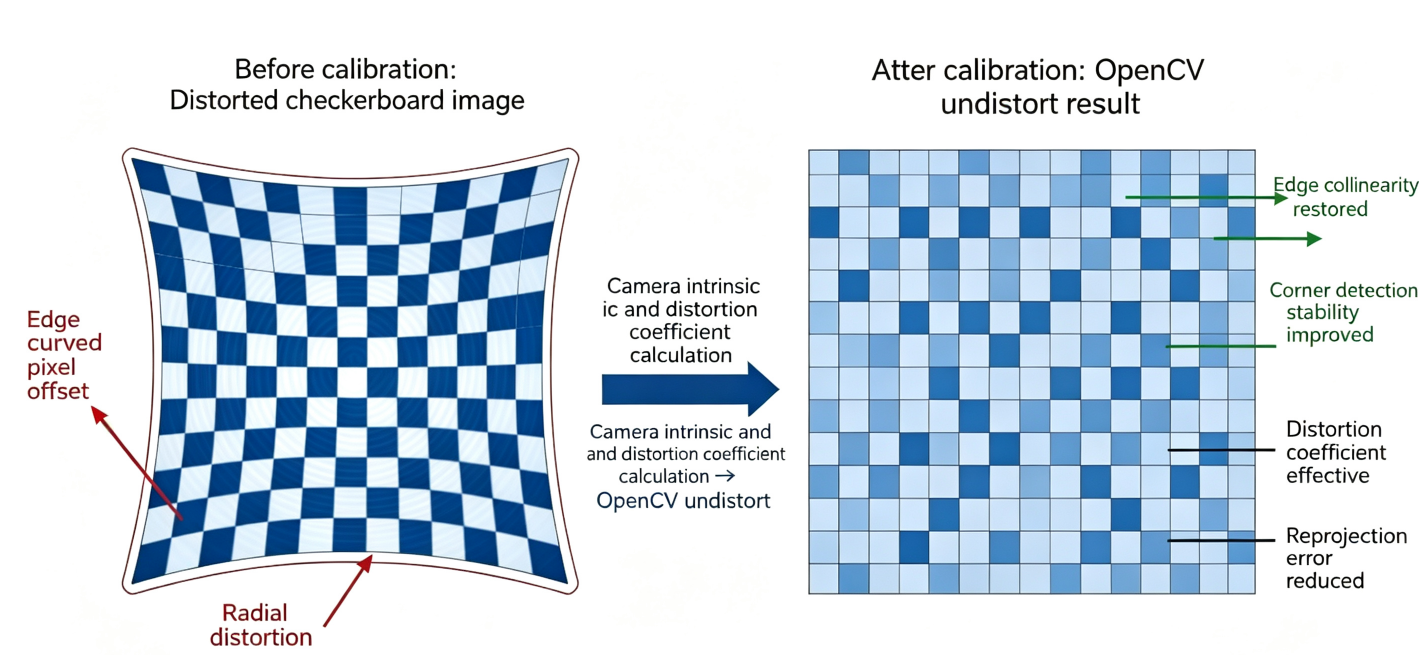
This paper reviews the OpenCV-based vision system for robotic-arm grasping across three core modules-camera calibration, image preprocessing and recognition, and binocular 3D reconstruction-together with lightweight deployment on embedded platforms. Using the calib3d module, monocular, binocular, and hand-eye calibration procedures are described, which correct lens distortion and unify coordinate frames and thereby address grasping-positioning errors. Image processing algorithms, including grayscale transformation, Gaussian and median filtering, Otsu segmentation, and feature matching, are compared for static and dynamic assembly-line scenarios. Binocular stereo matching generates disparity... More >

Graphical Abstract
A Review of Research and Applications of OpenCV in Robotic Arm Grasping Vision Systems
Free Access | Review Article | 20 September 2026
Lightweight YOLO Object Detection Algorithms for Vision-Based Robotic Arms: A Review
ICCK Transactions on Intelligent Cyber-Physical Systems | Volume 1, Issue 3: 97-103, 2026 | DOI: 10.62762/TICPS.2026.107157
Abstract
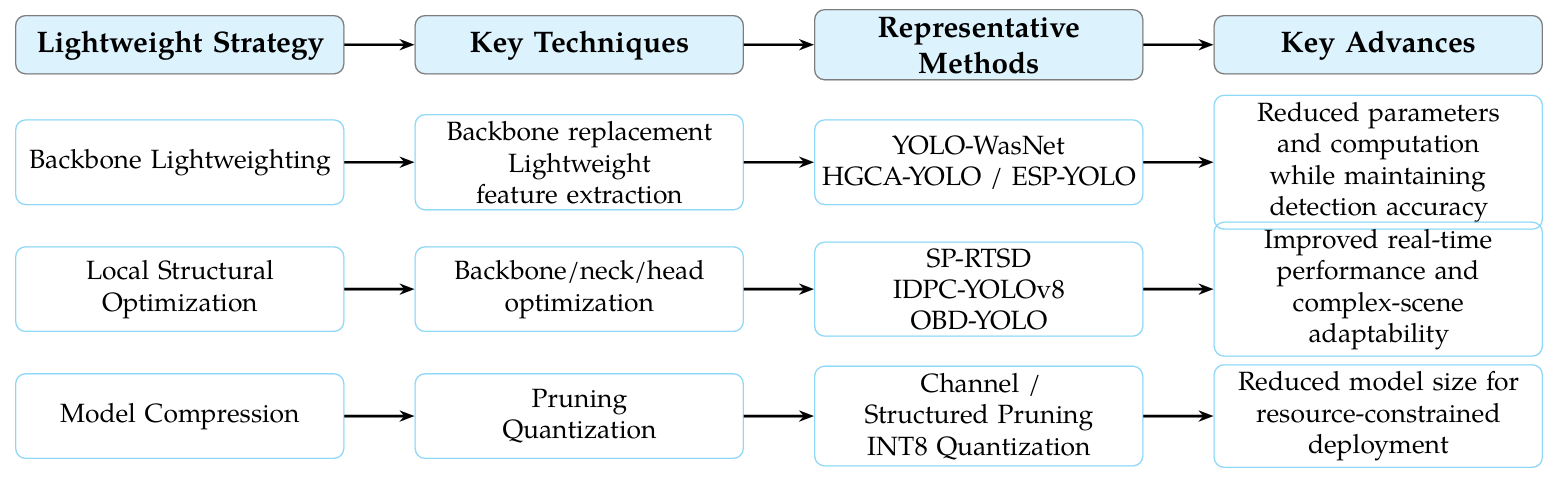
To address the requirements of vision-based robotic manipulators for object detection accuracy, real-time performance, and lightweight deployment, this paper reviews lightweight You Only Look Once (YOLO) object detection techniques and their applications in robotic vision. First, the main techniques, including structural lightweighting, model compression, and edge deployment, are summarized. Representative algorithms for vision-based robotic manipulators are then categorized into three groups: backbone lightweighting, local structural optimization, and model compression, with their detection performance and lightweighting characteristics analyzed. On this basis, the limitations of existing m... More >

Graphical Abstract
Lightweight YOLO Object Detection Algorithms for Vision-Based Robotic Arms: A Review
Free Access | Review Article | 16 September 2026
Advances in ROS-Based Robot Simulation Technology: A Mini Review
ICCK Transactions on Intelligent Cyber-Physical Systems | Volume 1, Issue 3: 93-96, 2026 | DOI: 10.62762/TICPS.2026.304297
Abstract
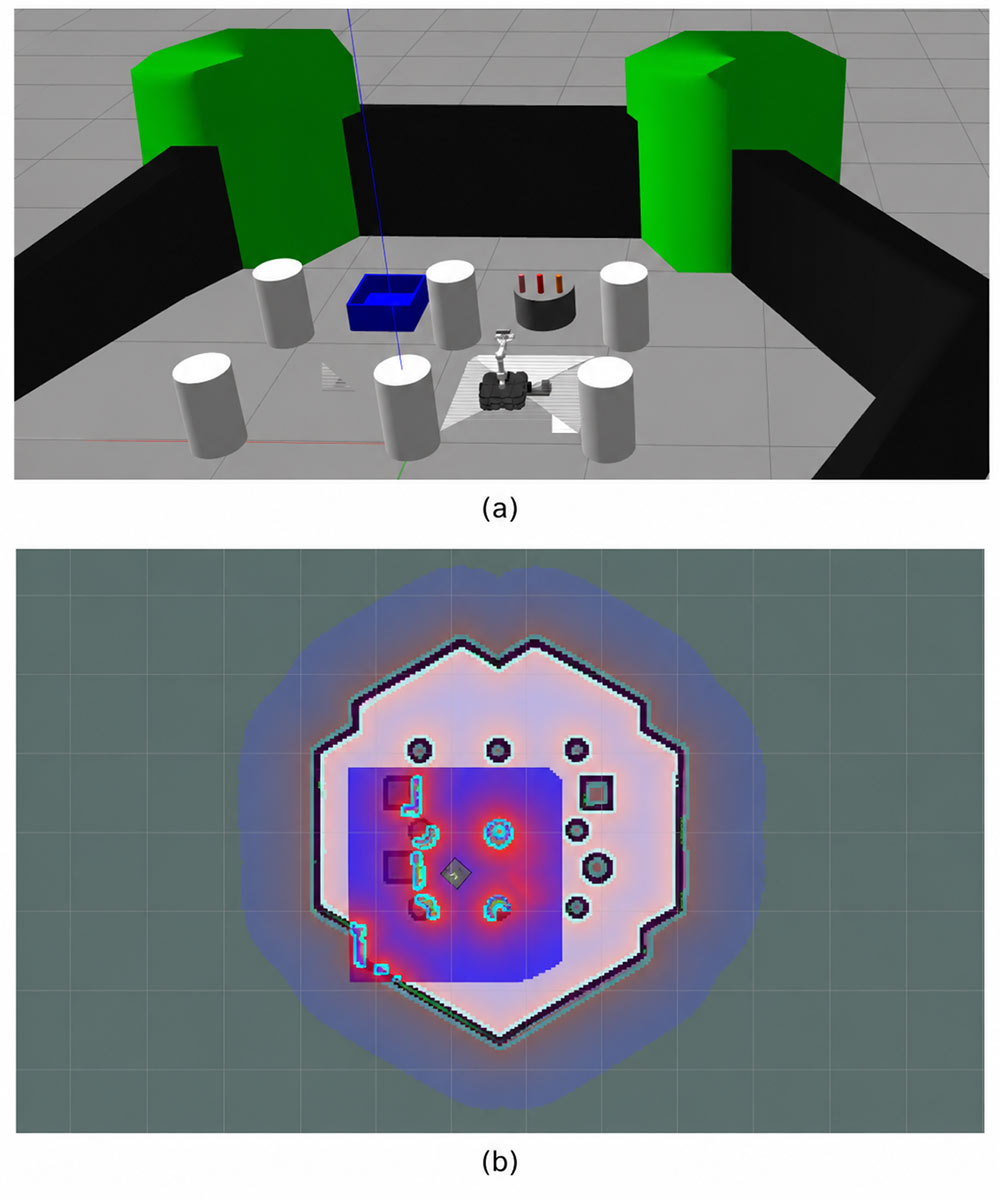
Robot simulation provides a repeatable and risk-controlled environment for developing increasingly integrated robotic systems. Within this field, the Robot Operating System (ROS) links robot models, sensors, controllers, and algorithms through modular communication interfaces and has formed a broad ecosystem with simulators such as Gazebo, Webots, and NVIDIA Isaac Sim. Recent progress has shifted from basic rigid-body and sensor simulation toward ROS~2-based interface unification, high-fidelity perception, GPU-accelerated synthetic-data generation, and Sim-to-Real transfer. This paper reviews these advances, discusses key developments in modeling, navigation, manipulation, and sensor simulat... More >

Graphical Abstract
Advances in ROS-Based Robot Simulation Technology: A Mini Review
Open Access | Research Article | 09 September 2026
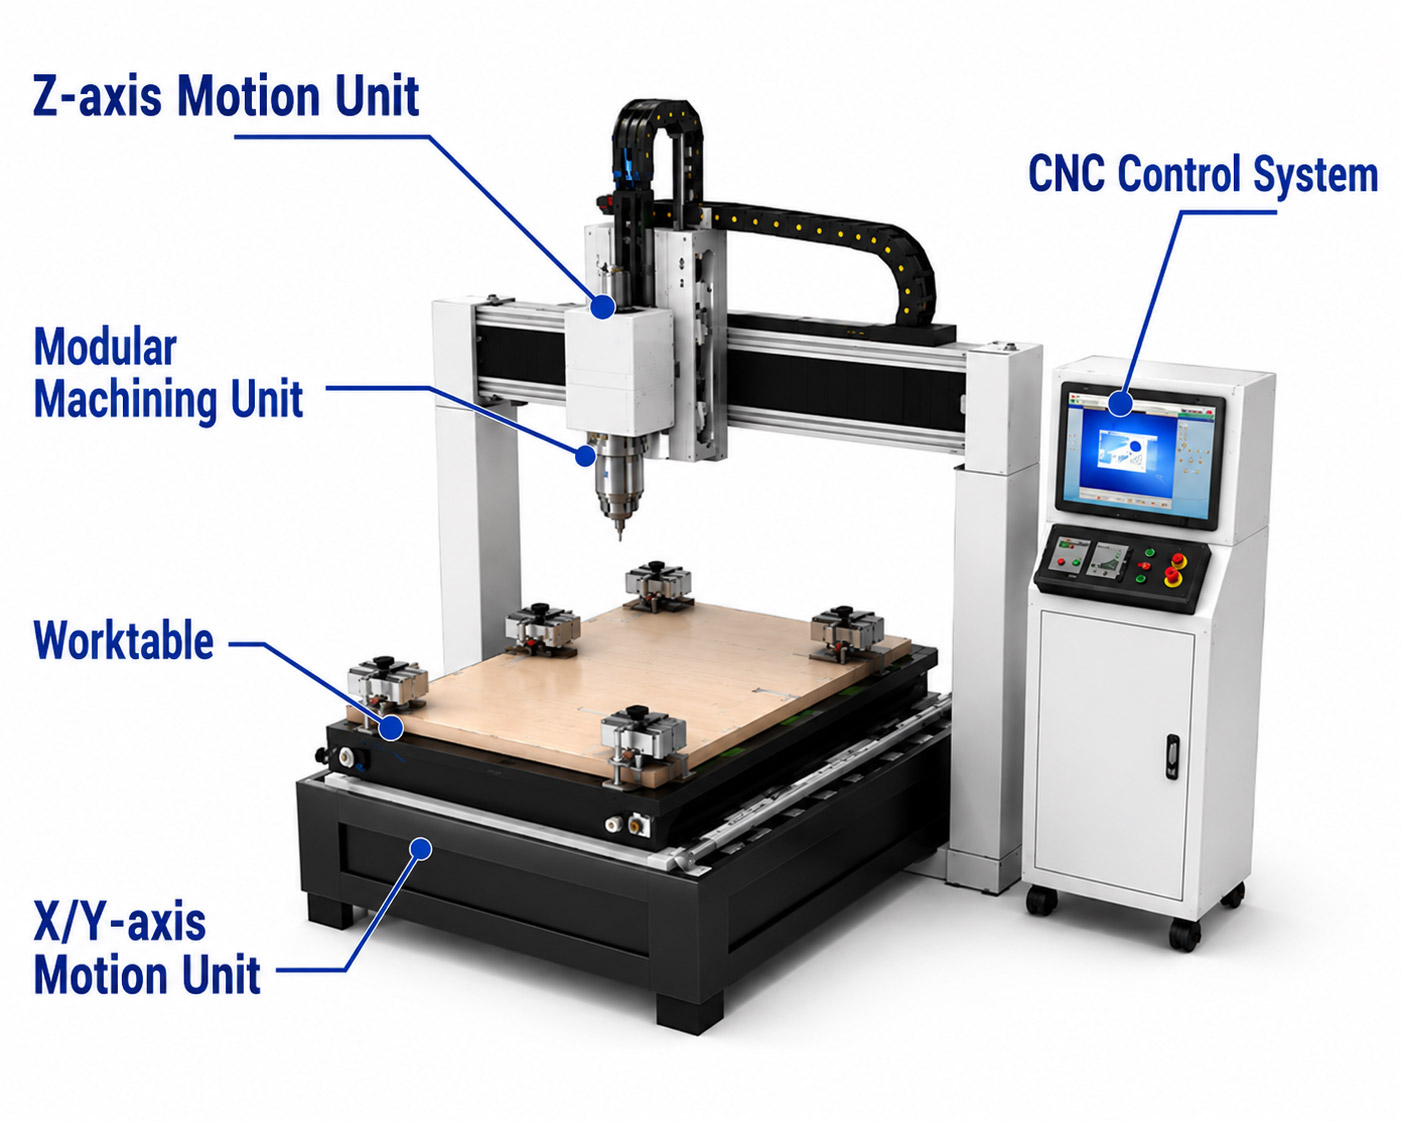
Design and Performance Evaluation of Flexible CNC Machining Equipment for Panel Furniture Manufacturing
ICCK Transactions on Intelligent Cyber-Physical Systems | Volume 1, Issue 3: 86-92, 2026 | DOI: 10.62762/TICPS.2026.403794
Abstract
A flexible CNC machining system is developed for panel furniture manufacturing to improve equipment adaptability and reduce non-machining time in customized production. The proposed system integrates a modular machining structure, multi-axis motion platform, automatic positioning fixtures, and a digital control system to enable flexible drilling and grooving operations. A machining path optimization strategy is introduced to reduce unnecessary tool movements. Experiments on medium-density fiberboard (MDF) panels demonstrate that the optimized method reduces machining time from 986~s to 654~s for 20 machining tasks and from 1248~s to 812~s for 25 tasks. The proposed equipment achieves a posit... More >

Graphical Abstract
Design and Performance Evaluation of Flexible CNC Machining Equipment for Panel Furniture Manufacturing