Advances in ROS-Based Robot Simulation Technology: A Mini Review

Article Information
Abstract
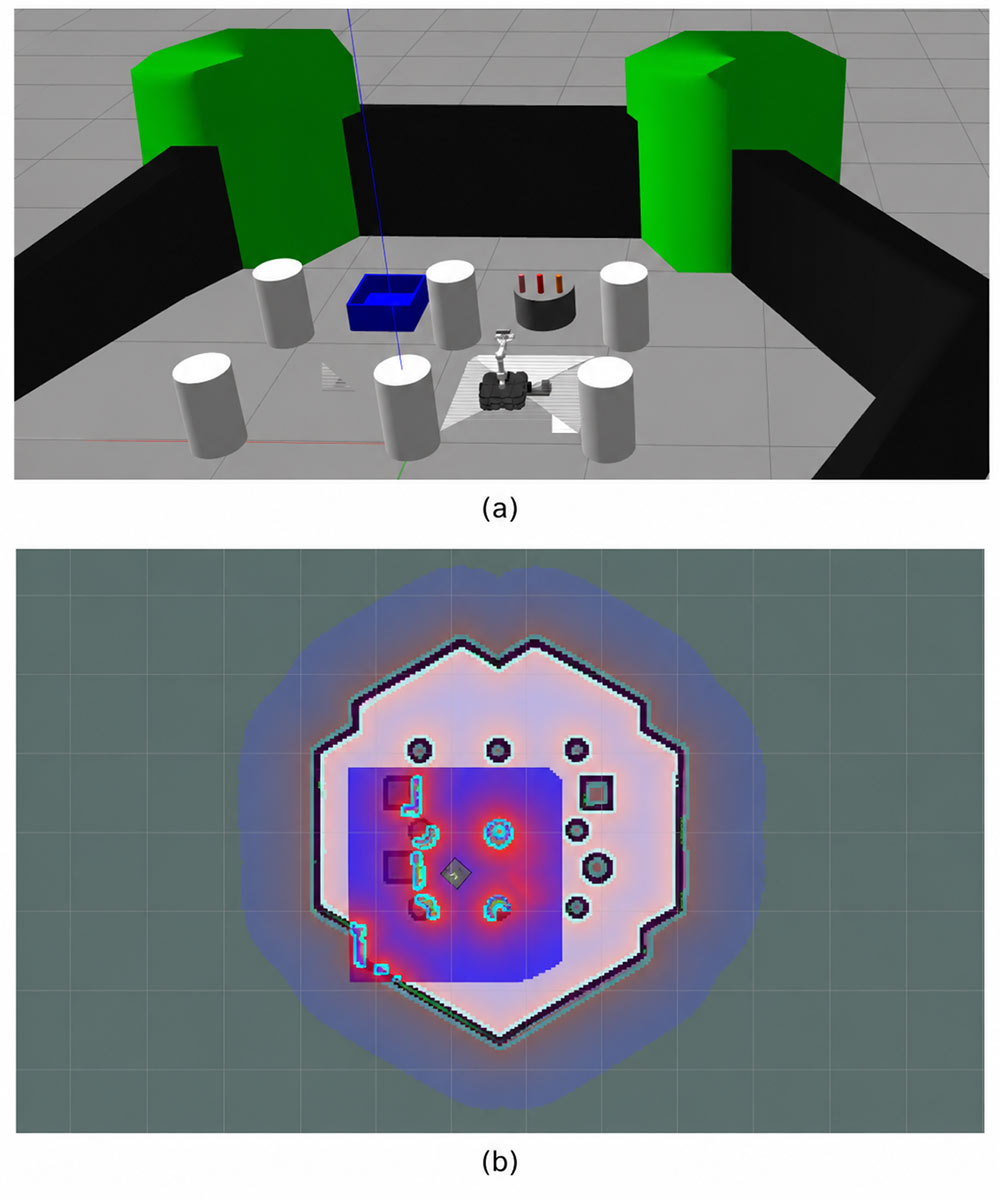
Robot simulation provides a repeatable and risk-controlled environment for developing increasingly integrated robotic systems. Within this field, the Robot Operating System (ROS) links robot models, sensors, controllers, and algorithms through modular communication interfaces and has formed a broad ecosystem with simulators such as Gazebo, Webots, and NVIDIA Isaac Sim. Recent progress has shifted from basic rigid-body and sensor simulation toward ROS~2-based interface unification, high-fidelity perception, GPU-accelerated synthetic-data generation, and Sim-to-Real transfer. This paper reviews these advances, discusses key developments in modeling, navigation, manipulation, and sensor simulation, and summarizes remaining challenges in fidelity, real-time performance, and virtual--real consistency.
Graphical Abstract
Keywords
Data Availability Statement
Funding
Conflicts of Interest
AI Use Statement
Ethical Approval and Consent to Participate
References
- Collins, J., Chand, S., Vanderkop, A., & Howard, D. (2021). A review of physics simulators for robotic applications. IEEE Access, 9, 51416--51431.
[CrossRef] [Google Scholar] - Quigley, M., Conley, K., Gerkey, B., Faust, J., Foote, T., Leibs, J., ... & Ng, A. Y. (2009, May). ROS: an open-source Robot Operating System. In ICRA workshop on open source software (Vol. 3, No. 3.2, p. 5). http://lars.mec.ua.pt/public/LAR%20Projects/BinPicking/2016_RodrigoSalgueiro/LIB/ROS/icraoss09-ROS.pdf
[Google Scholar] - Koenig, N., & Howard, A. (2004, September). Design and use paradigms for gazebo, an open-source multi-robot simulator. In 2004 IEEE/RSJ international conference on intelligent robots and systems (IROS)(IEEE Cat. No. 04CH37566) (Vol. 3, pp. 2149-2154). IEEE.
[CrossRef] [Google Scholar] - Macenski, S., Foote, T., Gerkey, B., Lalancette, C., & Woodall, W. (2022). Robot operating system 2: Design, architecture, and uses in the wild. Science robotics, 7(66), eabm6074.
[CrossRef] [Google Scholar] - Chitta, S., Marder-Eppstein, E., Meeussen, W., Pradeep, V., Tsouroukdissian, A. R., Bohren, J., ... & Perdomo, E. F. (2017). ros\_control: A generic and simple control framework for ROS. Journal of Open Source Software, 2(20), 456-456.
[CrossRef] [Google Scholar] - Farley, A., Wang, J., & Marshall, J. A. (2022). How to pick a mobile robot simulator: A quantitative comparison of CoppeliaSim, Gazebo, MORSE and Webots with a focus on accuracy of motion. Simulation Modelling Practice and Theory, 120, 102629.
[CrossRef] [Google Scholar] - Michel, O. (2004). Cyberbotics ltd. webots™: professional mobile robot simulation. International Journal of Advanced Robotic Systems, 1(1), 5.
[CrossRef] [Google Scholar] - NVIDIA. (2026). Isaac Sim Documentation: ROS 2 Tutorials. NVIDIA Corporation. Retrieved from https://docs.isaacsim.omniverse.nvidia.com/latest/ros2_tutorials/index.html
[Google Scholar] - Tobin, J., Fong, R., Ray, A., Schneider, J., Zaremba, W., & Abbeel, P. (2017, September). Domain randomization for transferring deep neural networks from simulation to the real world. In 2017 IEEE/RSJ international conference on intelligent robots and systems (IROS) (pp. 23-30). IEEE.
[CrossRef] [Google Scholar] - Zhao, W., Queralta, J. P., & Westerlund, T. (2020, December). Sim-to-real transfer in deep reinforcement learning for robotics: a survey. In 2020 IEEE symposium series on computational intelligence (SSCI) (pp. 737-744). IEEE.
[CrossRef] [Google Scholar] - Han, X., Yu, J., Liu, M., Chen, Y., Lyu, X., Tian, Y., ... & Pang, J. (2025). Re \$\^{ 3\$ Sim: Generating High-Fidelity Simulation Data via 3D-Photorealistic Real-to-Sim for Robotic Manipulation. arXiv preprint arXiv:2502.08645.
[CrossRef] [Google Scholar]
Cite This Article
TY  - JOUR
AU  - Zhou, Hui
PY  - 2026
DA  - 2026/09/16
TI  - Advances in ROS-Based Robot Simulation Technology: A Mini Review
JO  - ICCK Transactions on Intelligent Cyber-Physical Systems
T2  - ICCK Transactions on Intelligent Cyber-Physical Systems
JF  - ICCK Transactions on Intelligent Cyber-Physical Systems
VL  - 1
IS  - 3
SP  - 93
EP  - 96
DO  - 10.62762/TICPS.2026.304297
UR  - https://www.icck.org/article/abs/TICPS.2026.304297
KW  - ROS
KW  - ROS 2
KW  - robot simulation
KW  - Gazebo
KW  - Sim-to-Real
KW  - virtual-real integration
AB  - Robot simulation provides a repeatable and risk-controlled environment for developing increasingly integrated robotic systems. Within this field, the Robot Operating System (ROS) links robot models, sensors, controllers, and algorithms through modular communication interfaces and has formed a broad ecosystem with simulators such as Gazebo, Webots, and NVIDIA Isaac Sim. Recent progress has shifted from basic rigid-body and sensor simulation toward ROS~2-based interface unification, high-fidelity perception, GPU-accelerated synthetic-data generation, and Sim-to-Real transfer. This paper reviews these advances, discusses key developments in modeling, navigation, manipulation, and sensor simulation, and summarizes remaining challenges in fidelity, real-time performance, and virtual--real consistency.
SN  - 3071-2947
PB  - Institute of Central Computation and Knowledge
LA  - English
ER  -
@article{Zhou2026Advances,
  author = {Hui Zhou},
  title = {Advances in ROS-Based Robot Simulation Technology: A Mini Review},
  journal = {ICCK Transactions on Intelligent Cyber-Physical Systems},
  year = {2026},
  volume = {1},
  number = {3},
  pages = {93-96},
  doi = {10.62762/TICPS.2026.304297},
  url = {https://www.icck.org/article/abs/TICPS.2026.304297},
  abstract = {Robot simulation provides a repeatable and risk-controlled environment for developing increasingly integrated robotic systems. Within this field, the Robot Operating System (ROS) links robot models, sensors, controllers, and algorithms through modular communication interfaces and has formed a broad ecosystem with simulators such as Gazebo, Webots, and NVIDIA Isaac Sim. Recent progress has shifted from basic rigid-body and sensor simulation toward ROS~2-based interface unification, high-fidelity perception, GPU-accelerated synthetic-data generation, and Sim-to-Real transfer. This paper reviews these advances, discusses key developments in modeling, navigation, manipulation, and sensor simulation, and summarizes remaining challenges in fidelity, real-time performance, and virtual--real consistency.},
  keywords = {ROS, ROS 2, robot simulation, Gazebo, Sim-to-Real, virtual-real integration},
  issn = {3071-2947},
  publisher = {Institute of Central Computation and Knowledge}
}
Article Metrics
Publisher's Note
ICCK stays neutral with regard to jurisdictional claims in published maps and institutional affiliations.
Rights and Permissions
Portico
