ICCK

Professor Chengxi Zhang

Jiangnan University, Wuxi, China, CN

ORCID
Section 01

Academic Profile

Chengxi Zhang received B.S. and M.S. degrees from Harbin Institute of Technology, China, in 2012 and 2015; and Ph.D. degree from Shanghai Jiao Tong University, China, in 2019. He is now an Associate Professor at Jiangnan University, China. His interests are space engineering, robotic systems & control. He is the Editor-in-Chief of Aerospace Engineering Communications, an Associate Editor of Frontiers in Aerospace Engineering, Frontiers in Mechanical Engineering, on the Editorial Board of Scientific Reports, Symmetry and Aerospace Systems. He is a Committee Member of the Youth Working Committee, Chinese Association of Automation since 2025. He is listed in the World Top 2% Scientists in 2023, 2024 and 2025, by John P.A. Ioannidis, Stanford University, and Elsevier. He is a Senior Member of IEEE.

Section 02

ICCK Publications

Export all 3 BibTeX RIS
Open Access | Research Article | 21 September 2026
Event-Triggered Attitude Control of Underactuated Spacecraft
Aerospace Engineering Communications | Volume 1, Issue 3: 110-118, 2026 | DOI: 10.62762/AEC.2026.732691
Abstract
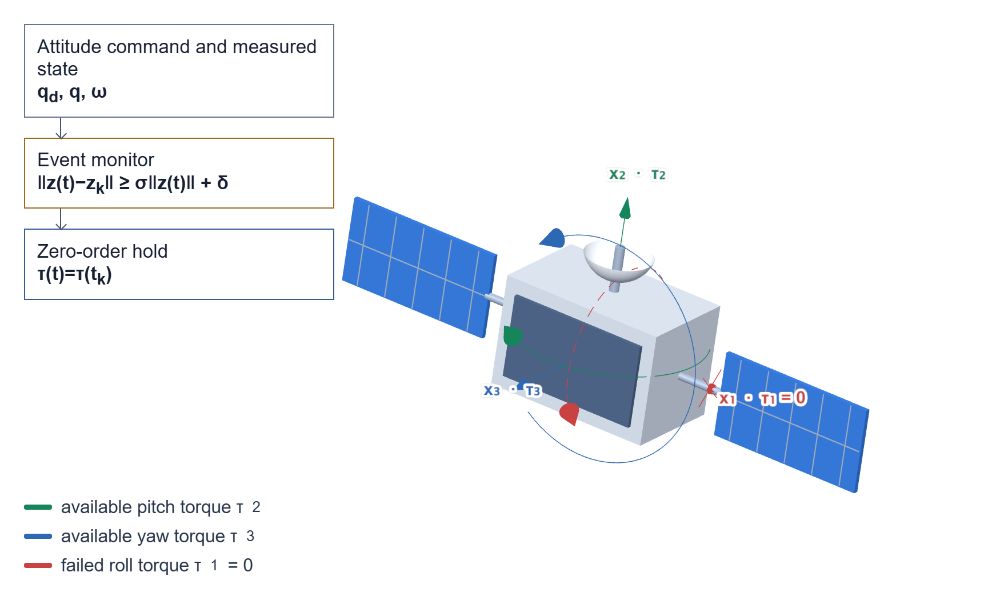
This paper presents an event-triggered attitude control method for an underactuated spacecraft with only two bounded body-axis torques. Gyroscopic coupling supplies the missing control action: two periodic angular-rate references generate the average gyroscopic rate product required to regulate the unactuated axis. A relative-plus-absolute event condition updates the bounded torque command, while a zero-order hold and a timeout provide implementable inter-event intervals. An elementary energy argument establishes asymptotic stability of the explicitly defined nominal averaged local error model, while a nonlinear simulation assesses the complete implementation. Under a 2 N$\cdot$m torque lim... More >

Graphical Abstract
Event-Triggered Attitude Control of Underactuated Spacecraft
Open Access | Research Article | 29 January 2026 | Cited: Scopus 1
Self-Learning Control under Practical Actuation
Aerospace Engineering Communications | Volume 1, Issue 1: 36-46, 2026 | DOI: 10.62762/AEC.2025.320719
Abstract
This paper develops a general and implementation friendly stability framework for self-learning control (SLC) laws of the form $u(t)=k_1(t)u(t-\tau)+k_2 v(t)$. Uniform ultimate boundedness is established for a class of general linear plants under two engineering actuator assumptions: (i) smoothness and (ii) saturation with maximum value. These assumptions are reasonable for practical systems and yield an explicit bound, which converts the delay learning mechanism into a nominal (delay-free) controller plus a bounded perturbation injection. The most notable feature of SLC is its simplicity of structure coupled with excellent performance. It is compatible with traditional algorithms and can e... More >

Graphical Abstract
Self-Learning Control under Practical Actuation
Open Access | Editorial | 22 November 2025 | Cited: Crossref logo  1
Charting the Future of Aerospace
Aerospace Engineering Communications | Volume 1, Issue 1: 1-2, 2025 | DOI: 10.62762/AEC.2025.971687
Abstract
Inaugural Editorial: A welcome message from the Editor-in-Chief of Aerospace Engineering Communications. More >