ICCK

Yiyang Ni

Jiangsu Second Normal University

Section 01

Academic Profile

No academic profile information available at the moment.

Section 02

Editorial Roles

This user currently does not serve as an editor for any ICCK journals.

Section 03

ICCK Publications

Open Access | Research Article | 26 September 2026
Communication Topology Resilience-Guided Optimization for Multi-UAV Cooperative Planning
Aerospace Engineering Communications | Volume 1, Issue 3: 128-136, 2026 | DOI: 10.62762/AEC.2026.595594
Abstract
This paper studies cooperative mission planning for multi-unmanned aerial vehicle (UAV) swarms in obstacle-cluttered environments, with particular attention to mission feasibility and communication-topology resilience. Considering that task assignment and waypoint selection directly affect the inter-UAV communication graph, a communication topology resilience-guided (CTR) method is proposed by introducing algebraic connectivity as an explicit topology metric. The method first performs topology-guided one-to-one task assignment using simulated annealing, jointly considering normalized distance, obstacle risk, and algebraic connectivity. It then selects topology-aware key waypoints according t... More >

Graphical Abstract
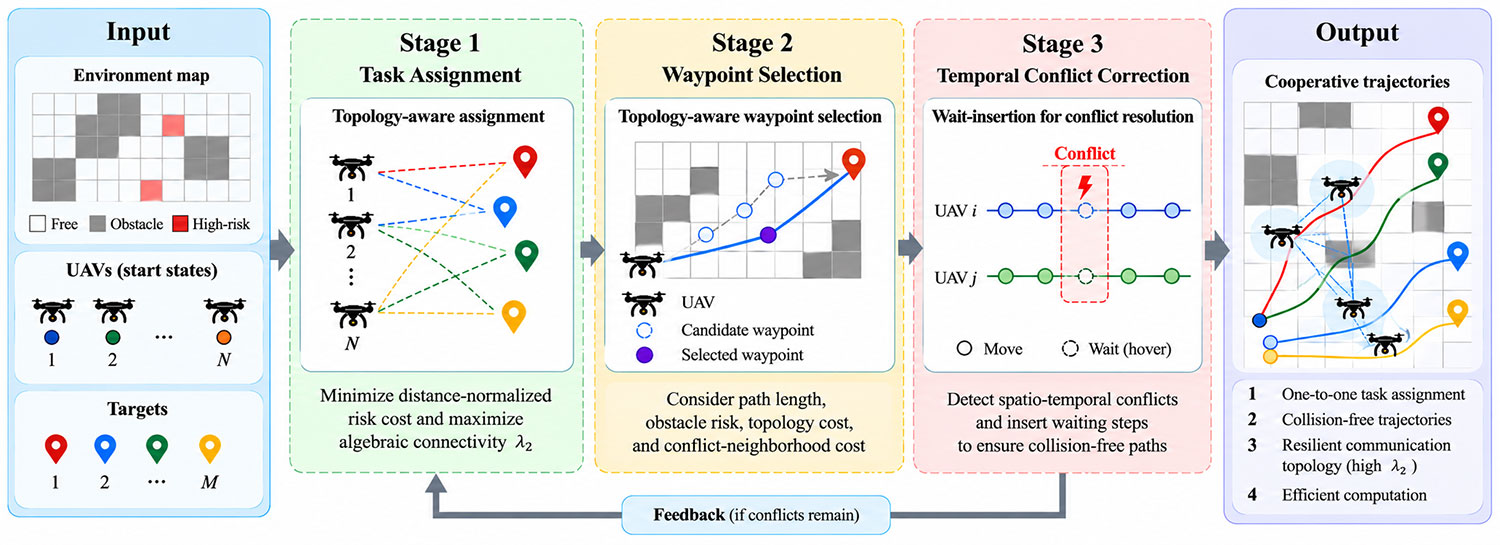
Communication Topology Resilience-Guided Optimization for Multi-UAV Cooperative Planning
Open Access | Research Article | 25 January 2026
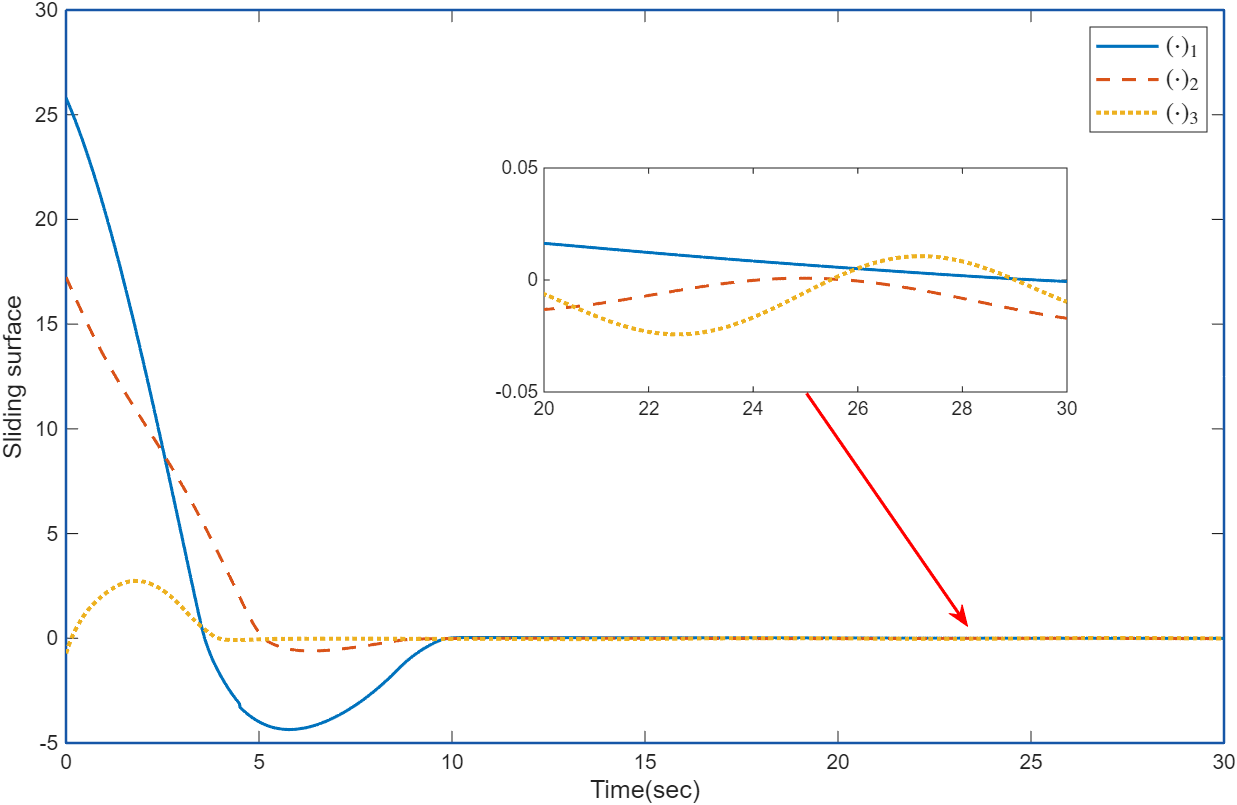
Adaptive Finite-Time Attitude Control Based on Time-Varying Sliding Mode
Aerospace Engineering Communications | Volume 1, Issue 1: 28-35, 2026 | DOI: 10.62762/AEC.2025.182476
Abstract
This study investigates the finite-time attitude tracking problem of spacecraft. We employ finite-time control methods to develop a novel adaptive controller. The controller utilizes a time-varying non-singular adaptive fast terminal sliding mode. The time-varying sliding mode dynamically adjusts the sliding surface morphology. This adjustment enables precise control performance tuning. Additionally, adaptive methods estimate the upper bound of generalized disturbances. This estimation reduces the computational load of the controller. The proposed controller demonstrates high robustness against external disturbances and inertia uncertainties. Lyapunov methods prove the stability of the contr... More >

Graphical Abstract
Adaptive Finite-Time Attitude Control Based on Time-Varying Sliding Mode