

Aerospace Engineering Communications | Volume 1, Issue 3: 128-136, 2026 | DOI: 10.62762/AEC.2026.595594
Abstract
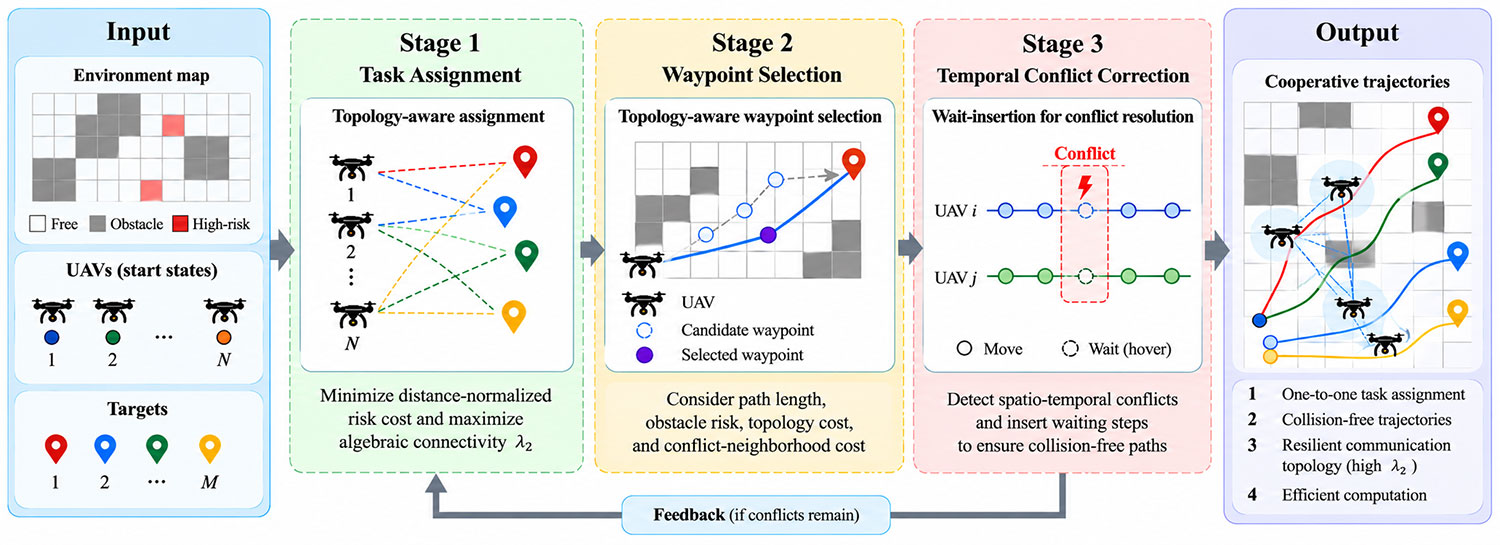
This paper studies cooperative mission planning for multi-unmanned aerial vehicle (UAV) swarms in obstacle-cluttered environments, with particular attention to mission feasibility and communication-topology resilience. Considering that task assignment and waypoint selection directly affect the inter-UAV communication graph, a communication topology resilience-guided (CTR) method is proposed by introducing algebraic connectivity as an explicit topology metric. The method first performs topology-guided one-to-one task assignment using simulated annealing, jointly considering normalized distance, obstacle risk, and algebraic connectivity. It then selects topology-aware key waypoints according t... More >
Graphical Abstract