 0, 0 | Viewed: 1395, Download: 455

Aerospace Engineering Communications | Volume 1, Issue 3: 110-118, 2026 | DOI: 10.62762/AEC.2026.732691
Abstract
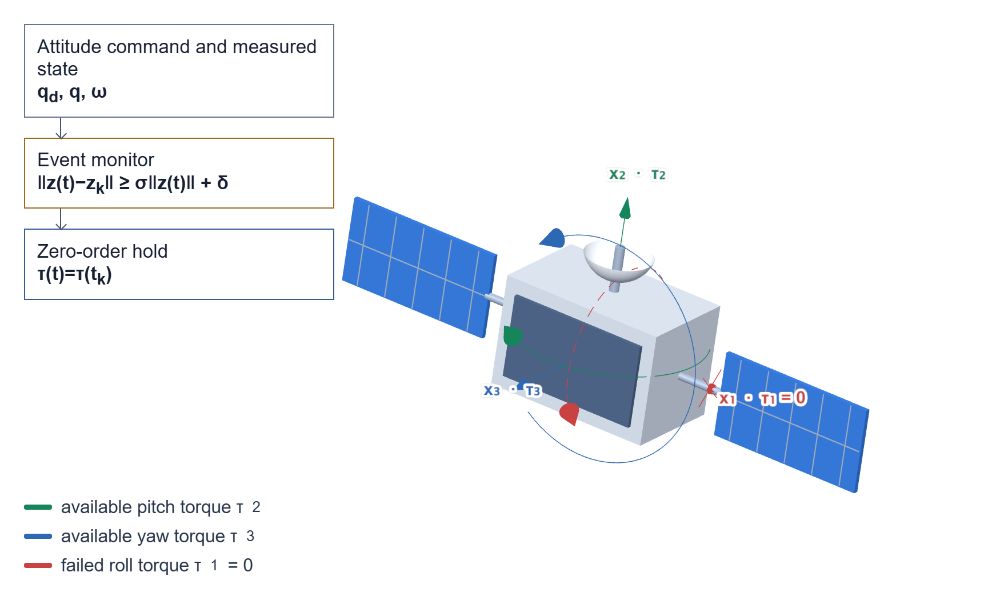
This paper presents an event-triggered attitude control method for an underactuated spacecraft with only two bounded body-axis torques. Gyroscopic coupling supplies the missing control action: two periodic angular-rate references generate the average gyroscopic rate product required to regulate the unactuated axis. A relative-plus-absolute event condition updates the bounded torque command, while a zero-order hold and a timeout provide implementable inter-event intervals. An elementary energy argument establishes asymptotic stability of the explicitly defined nominal averaged local error model, while a nonlinear simulation assesses the complete implementation. Under a 2 N$\cdot$m torque lim... More >
Graphical Abstract