
Artificial Intelligence in Aerial Unmanned Systems: A Comprehensive Review of Evolution, Applications, and Future Trends

Article Information
Abstract
Achieving carbon neutrality in the aviation sector demands transformative technologies, and Artificial Intelligence (AI)-enabled aerial unmanned systems are emerging as a critical enabler of low-carbon flight operations, environmental monitoring, and sustainable airspace governance, yet a comprehensive synthesis that jointly addresses their technical architecture, climate-oriented applications, and regulatory pathways remains limited. This review provides a systematic analysis of AI-enabled aerial unmanned systems using a structured literature review framework aligned with PRISMA principles. We first summarize the evolution and classification of aerial unmanned platforms, then propose a layered technical perspective covering perception, decision-making, control, collaboration, and support capabilities. On this basis, we map representative advances in military and civilian scenarios, including autonomous navigation, multi-UAV cooperation, infrastructure inspection, emergency response, and logistics operations. A dedicated discussion further examines AI-driven decarbonization pathways, showing how intelligent energy management and trajectory optimization, together with UAV-based environmental sensing, can contribute to low-carbon aviation and climate-oriented operations. We also identify major barriers to large-scale deployment, including robustness in complex environments, edge intelligence constraints, explainability and trust, cybersecurity, regulatory compliance, and interdisciplinary talent gaps. Finally, we outline future directions centered on embodied intelligence, stronger onboard computing, swarm-level autonomy, and internationally harmonized standards. This review offers an integrated roadmap for researchers, engineers, and policymakers to advance safe, scalable, and sustainable AI-enabled unmanned aviation.
Graphical Abstract
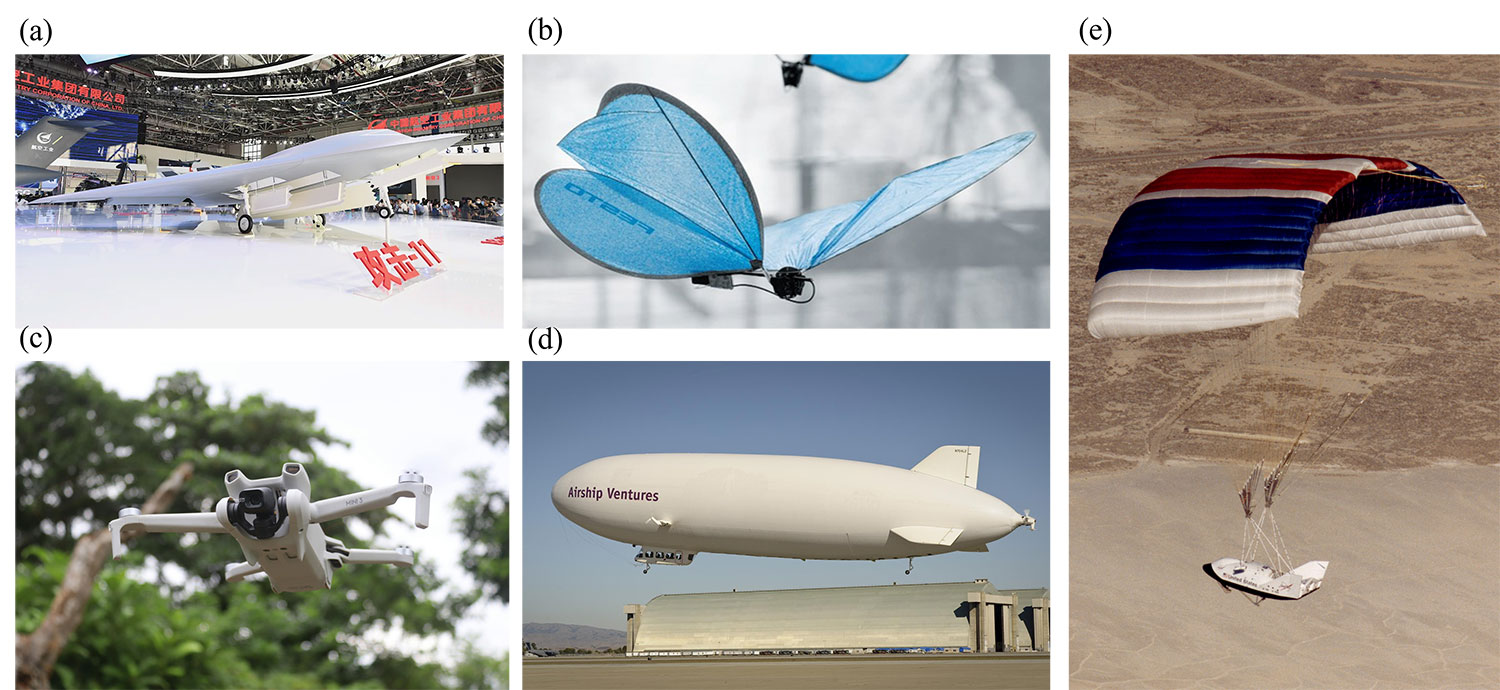
Keywords
Data Availability Statement
Funding
Conflicts of Interest
AI Use Statement
Ethical Approval and Consent to Participate
References
- U.S. Department of Defense. (2018). Unmanned systems integrated roadmap (Fiscal Years 2017-2042) [National policy document]. U.S. Department of Defense. Retrieved from https://news.usni.org/2018/08/30/pentagon-unmanned-systems-integrated-roadmap-2017-2042
[Google Scholar] - Government of the Russian Federation. (2023). Strategy for the development of unmanned aircraft until 2030 [National strategy document]. Ministry of Industry and Trade of the Russian Federation. Retrieved from https://globaltradealert.org/state-act/76548-russia-strategy-for-the-development-of-unmanned-aircraft-until-2030/
[Google Scholar] - Ministry of Industry and Information Technology of the People's Republic of China, Civil Aviation Administration of China, & National Development and Reform Commission. (2024). Implementation plan for the innovative application of general aviation equipment (2024-2030) [National policy document]. State Council of the People's Republic of China. Retrieved from https://www.gov.cn/zhengce/zhengceku/202403/content_6942115.htm
[Google Scholar] - Ali, S., Abu-Samah, A., Abdullah, N. F., & Mohd Kamal, N. L. (2024). Propagation modeling of unmanned aerial vehicle (UAV) 5G wireless networks in rural mountainous regions using ray tracing. Drones, 8(7), 334.
[CrossRef] [Google Scholar] - Tang, D., & Zhang, Q. (2024). UAV 5G: enabled wireless communications using enhanced deep learning for edge devices. Wireless Networks, 30(8), 7123-7136.
[CrossRef] [Google Scholar] - Guo, H., Wang, Y., Liu, J., & Liu, C. (2023). Multi-UAV cooperative task offloading and resource allocation in 5G advanced and beyond. IEEE Transactions on Wireless Communications, 23(1), 347-359.
[CrossRef] [Google Scholar] - Badshah, A., Daud, A., Aboulola, O. I., Bukhari, A., Alshemaimri, B., & Dawood, H. (2025). Network optimization by regional computing for UAVs' big data. Frontiers in Computer Science, 7, 1565716.
[CrossRef] [Google Scholar] - Li, J., He, Y., Zhang, X., & Wu, Q. (2021). Simultaneous localization of multiple unknown emitters based on UAV monitoring big data. IEEE Transactions on Industrial Informatics, 17(9), 6303-6313.
[CrossRef] [Google Scholar] - Market Growth Reports. (2026, January 5). Artificial intelligence in aviation market size, share, growth, and industry analysis, by type (hardware, software, service), by application (virtual assistants, smart maintenance), regional insights and forecast to 2035 [Market report]. Market Growth Reports. Retrieved from https://www.marketgrowthreports.com/market-reports/artificial-intelligence-in-aviation-market-102603
[Google Scholar] - Fortunebusinessinsights. (2026, January 5). AI in aviation market [Market report, Report No. FBI113289]. Fortunebusinessinsights. Retrieved from https://www.fortunebusinessinsights.com/zh/ai-in-aviation-market-113289
[Google Scholar] - Hamissi, A., & Dhraief, A. (2023). A survey on the unmanned aircraft system traffic management. ACM Computing Surveys, 56(3), 1-37.
[CrossRef] [Google Scholar] - Tepylo, N., Straubinger, A., & Laliberte, J. (2023). Public perception of advanced aviation technologies: A review and roadmap to acceptance. Progress in Aerospace Sciences, 138, 100899.
[CrossRef] [Google Scholar] - Asghari, O., Ivaki, N., & Madeira, H. (2025). UAV operations safety assessment: A systematic literature review. ACM Computing Surveys, 57(10), 1-37.
[CrossRef] [Google Scholar] - Bhat, G. R., Dudhedia, M. A., Panchal, R. A., Shirke, Y. S., Angane, N. R., Khonde, S. R., ... & Gawande, S. H. (2024). Autonomous drones and their influence on standardization of rules and regulations for operating–A brief overview. Results in Control and Optimization, 14, 100401.
[CrossRef] [Google Scholar] - Aposporis, P. (2024). A review of global and regional frameworks for the integration of an unmanned aircraft system in air traffic management. Transportation Research Interdisciplinary Perspectives, 24, 101064.
[CrossRef] [Google Scholar] - Wanner, D., Hashim, H. A., Srivastava, S., & Steinhauer, A. (2024). UAV avionics safety, certification, accidents, redundancy, integrity, and reliability: a comprehensive review and future trends. Drone Systems and Applications, 12(2024), 1–23.
[CrossRef] [Google Scholar] - Wiedemann, M., Liang, M., Keremane, G., & Quigley, K. (2024). Advanced Air Mobility: A comparative review of policies from around the world—lessons for Australia. Transportation research interdisciplinary perspectives, 24, 100988.
[CrossRef] [Google Scholar] - ElSayed, M., Foda, A., & Mohamed, M. (2024). The impact of civil airspace policies on the viability of adopting autonomous unmanned aerial vehicles in last-mile applications. Transport Policy, 145, 37-54.
[CrossRef] [Google Scholar] - Allouche, M. (2005). Recent European UAV Rule-Making Initiatives Reflections, Lessons Learned from IAI-Malat Participation. In Infotech@ Aerospace (p. 7035).
[CrossRef] [Google Scholar] - Xiang, S., Xie, A., Ye, M., Yan, X., Han, X., Niu, H., ... & Huang, H. (2024). Autonomous eVTOL: A summary of researches and challenges. Green Energy and Intelligent Transportation, 3(1), 100140.
[CrossRef] [Google Scholar] - Lyu, J. (2025). Key technologies and application progress of civil unmanned aerial vehicle. Advances in Engineering Innovation, 16(6), 84-88.
[CrossRef] [Google Scholar] - Sai, S., Garg, A., Jhawar, K., Chamola, V., & Sikdar, B. (2023). A comprehensive survey on artificial intelligence for unmanned aerial vehicles. IEEE Open Journal of Vehicular Technology, 4, 713-738.
[CrossRef] [Google Scholar] - Hassan, K., Thakur, A. K., Singh, G., Singh, J., Gupta, L. R., & Singh, R. (2024). Application of artificial intelligence in aerospace engineering and its future directions: A systematic quantitative literature review. Archives of Computational Methods in Engineering, 31(7), 4031-4086.
[CrossRef] [Google Scholar] - Kitchenham, B., & Charters, S. (2007). Guidelines for performing systematic literature reviews in software engineering. EBSE Technical Report EBSE-2007-01, Keele University and Durham University. https://www.researchgate.net/publication/302924724
[Google Scholar] - Tranfield, D., Denyer, D., & Smart, P. (2003). Towards a methodology for developing evidence-informed management knowledge by means of systematic review. British Journal of Management, 14(3), 207-222.
[CrossRef] [Google Scholar] - Page, M. J., McKenzie, J. E., Bossuyt, P. M., Boutron, I., Hoffmann, T. C., Mulrow, C. D., ... & Moher, D. (2021). The PRISMA 2020 statement: an updated guideline for reporting systematic reviews. bmj, 372.
[CrossRef] [Google Scholar] - Moher, D., Liberati, A., Tetzlaff, J., Altman, D. G., & PRISMA Group*, T. (2009). Preferred reporting items for systematic reviews and meta-analyses: the PRISMA statement. Annals of internal medicine, 151(4), 264-269.
[CrossRef] [Google Scholar] - Global Times. (2021, September 28). China’s GJ-11 stealth drone displays precision weapons at Airshow China 2021. Retrieved from https://www.globaltimes.cn/page/202109/1235283.shtml
[Google Scholar] - Festo. (n.d.). eMotionButterflies: Ultralight flying objects with collective behavior. Festo Bionic Learning Network. Retrieved from https://www.festo.com/us/en/e/about-festo/research-and-development/bionic-learning-network/bionic-flying-objects/emotionbutterflies-id_33454/
[Google Scholar] - DJI. (2018). Mavic 2 product information. DJI. Available online: https://www.dji.com/mavic-2/info
[Google Scholar] - NASA. (2008). ARC-2008-ACD08-0265-089. NASA Image and Video Library. Available online: https://images.nasa.gov/details/ARC-2008-ACD08-0265-089.
[Google Scholar] - NASA. (1999). EC99-44923-140. NASA Image and Video Library. Available online: https://images.nasa.gov/details/EC99-44923-140.
[Google Scholar] - Kim, S., Hsiao, Y. H., Ren, Z., Huang, J., & Chen, Y. (2025). Acrobatics at the insect scale: A durable, precise, and agile micro–aerial robot. Science robotics, 10(98), eadp4256.
[CrossRef] [Google Scholar] - JD Logistics. (n.d.). JDX-50 logistics drone product webpage. JD Logistics. Available online: https://www.jdl.com/JDX50/.
[Google Scholar] - DJI Agriculture. (2025). T100S & T70S agricultural drones. SZ DJI Technology Co., Ltd. Available online: https://ag.dji.com/cn/t100s.
[Google Scholar] - United Aircraft. (n.d.). TD550 coaxial unmanned helicopter. Shenzhen United Aircraft Technology Co., Ltd. Available online: https://www.uatair.com/product/info/25.html.
[Google Scholar] - Haenlein, M., & Kaplan, A. (2019). A brief history of artificial intelligence: On the past, present, and future of artificial intelligence. California management review, 61(4), 5-14.
[CrossRef] [Google Scholar] - Zhu, P., Wen, L., Du, D., Bian, X., Fan, H., Hu, Q., & Ling, H. (2021). Detection and tracking meet drones challenge. IEEE transactions on pattern analysis and machine intelligence, 44(11), 7380-7399.
[CrossRef] [Google Scholar] - Bouguettaya, A., Zarzour, H., Kechida, A., & Taberkit, A. M. (2023). A survey on deep learning-based identification of plant and crop diseases from UAV-based aerial images. Cluster Computing, 26(2), 1297-1317.
[CrossRef] [Google Scholar] - Hendrycks, D., & Dietterich, T. (2019). Benchmarking neural network robustness to common corruptions and perturbations. arXiv preprint arXiv:1903.12261.
[CrossRef] [Google Scholar] - Zhang, H., Zhang, H., Liu, K., Gan, Z., & Zhu, G. N. (2025, October). UAV-DETR: efficient end-to-end object detection for unmanned aerial vehicle imagery. In 2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) (pp. 15143-15149). IEEE.
[CrossRef] [Google Scholar] - Zheng, C., Xu, W., Zou, Z., Hua, T., Yuan, C., He, D., ... & Zhang, F. (2024). Fast-livo2: Fast, direct lidar–inertial–visual odometry. IEEE Transactions on Robotics, 41, 326-346.
[CrossRef] [Google Scholar] - Liu, P., Lu, H., Liu, H., Liu, H., Liu, X., Yao, R., ... & Ma, J. (2025). OmniScene: Attention-augmented multimodal 4D scene understanding for autonomous driving. arXiv preprint arXiv:2509.19973.
[CrossRef] [Google Scholar] - AlMahamid, F., & Grolinger, K. (2022). Autonomous unmanned aerial vehicle navigation using reinforcement learning: A systematic review. Engineering Applications of Artificial Intelligence, 115, 105321.
[CrossRef] [Google Scholar] - Zhang, L., Peng, J., Yi, W., Lin, H., Lei, L., & Song, X. (2023). A state-decomposition DDPG algorithm for UAV autonomous navigation in 3-D complex environments. IEEE Internet of Things Journal, 11(6), 10778-10790.
[CrossRef] [Google Scholar] - Garcıa, J., & Fernández, F. (2015). A comprehensive survey on safe reinforcement learning. Journal of Machine Learning Research, 16(1), 1437-1480. https://www.jmlr.org/papers/volume16/garcia15a/garcia15a.pdf
[Google Scholar] - Amodei, D., Olah, C., Steinhardt, J., Christiano, P., Schulman, J., & Mané, D. (2016). Concrete problems in AI safety. arXiv preprint arXiv:1606.06565.
[CrossRef] [Google Scholar] - Liu, Z., Cao, Y., Chen, J., & Li, J. (2022). A hierarchical reinforcement learning algorithm based on attention mechanism for UAV autonomous navigation. IEEE Transactions on Intelligent Transportation Systems, 24(11), 13309-13320.
[CrossRef] [Google Scholar] - He, L., Aouf, N., & Song, B. (2021). Explainable deep reinforcement learning for UAV autonomous path planning. Aerospace science and technology, 118, 107052.
[CrossRef] [Google Scholar] - Achiam, J., Held, D., Tamar, A., & Abbeel, P. (2017, July). Constrained policy optimization. In International conference on machine learning (pp. 22-31). Pmlr. https://proceedings.mlr.press/v70/achiam17a
[Google Scholar] - Ray, A., Achiam, J., & Amodei, D. (2019). Benchmarking safe exploration in deep reinforcement learning [Technical report]. OpenAI. https://cdn.openai.com/safexp-short.pdf
[Google Scholar] - Loquercio, A., Kaufmann, E., Ranftl, R., Müller, M., Koltun, V., & Scaramuzza, D. (2021). Learning high-speed flight in the wild. Science Robotics, 6(59), eabg5810.
[CrossRef] [Google Scholar] - Kaufmann, E., Bauersfeld, L., Loquercio, A., Müller, M., Koltun, V., & Scaramuzza, D. (2023). Champion-level drone racing using deep reinforcement learning. Nature, 620(7976), 982-987.
[CrossRef] [Google Scholar] - Yu, S., Jiang, H., Huang, S., Peng, X., & Lu, A. (2021). Compute-in-memory chips for deep learning: Recent trends and prospects. IEEE circuits and systems magazine, 21(3), 31-56.
[CrossRef] [Google Scholar] - Cao, P., Lei, L., Cai, S., Shen, G., Liu, X., Wang, X., ... & Guizani, M. (2024). Computational intelligence algorithms for UAV swarm networking and collaboration: A comprehensive survey and future directions. IEEE Communications Surveys & Tutorials, 26(4), 2684-2728.
[CrossRef] [Google Scholar] - Xia, B., Mantegh, I., & Xie, W. (2024). Decentralized UAV swarm control: A multi-layered architecture for integrated flight mode management and dynamic target interception. Drones, 8(8), 350.
[CrossRef] [Google Scholar] - Baneshi, F., Cerezo-Magaña, M., & Soler, M. (2025). Network-level aircraft trajectory planning via multi-agent deep reinforcement learning: Balancing climate considerations and operational manageability. Expert Systems with Applications, 271, 126604.
[CrossRef] [Google Scholar] - Zhao, H., Pan, F., Ping, H., & Zhou, Y. (2023). Agent as cerebrum, controller as cerebellum: Implementing an embodied lmm-based agent on drones. arXiv preprint arXiv:2311.15033.
[CrossRef] [Google Scholar] - Ping, Y., Liang, T., Ding, H., Lei, G., Wu, J., Zou, X., Shi, K., Shao, R., Zhang, C., Zhang, W., Yuan, W., & Zhang, T. (2025). Multimodal large language models-enabled UAV swarm: Towards efficient and intelligent autonomous aerial systems. IEEE Wireless Communications, 33(1), 89-97.
[CrossRef] [Google Scholar] - Sautenkov, O., Yaqoot, Y., Lykov, A., Mustafa, M. A., Tadevosyan, G., Akhmetkazy, A., ... & Tsetserukou, D. (2025, March). UAV-VLA: Vision-language-action system for large scale aerial mission generation. In 2025 20th ACM/IEEE International Conference on Human-Robot Interaction (HRI) (pp. 1588-1592). IEEE.
[CrossRef] [Google Scholar] - Boroujeni, S. P. H., Razi, A., Khoshdel, S., Afghah, F., Coen, J. L., O'Neill, L., ... & Vamvoudakis, K. G. (2024). A comprehensive survey of research towards AI-enabled unmanned aerial systems in pre-, active-, and post-wildfire management. Information Fusion, 108, 102369.
[CrossRef] [Google Scholar] - Kendoul, F. (2012). Survey of advances in guidance, navigation, and control of unmanned rotorcraft systems. Journal of Field Robotics, 29(2), 315-378.
[CrossRef] [Google Scholar] - Chen, J., Sun, J., & Wang, G. (2022). From unmanned systems to autonomous intelligent systems. Engineering, 12, 16-19.
[CrossRef] [Google Scholar] - Wu, C., & Zhang, T. (2020). Intelligent unmanned systems: important achievements and applications of new generation artificial intelligence. Frontiers of Information Technology & Electronic Engineering, 21(5), 649-651.
[CrossRef] [Google Scholar] - Parasuraman, R., Sheridan, T. B., & Wickens, C. D. (2000). A model for types and levels of human interaction with automation. IEEE Transactions on systems, man, and cybernetics-Part A: Systems and Humans, 30(3), 286-297.
[CrossRef] [Google Scholar] - Chen, H., Wen, Y., Zhu, M., Huang, Y., Xiao, C., Wei, T., & Hahn, A. (2021). From automation system to autonomous system: An architecture perspective. Journal of Marine Science and Engineering, 9(6), 645.
[CrossRef] [Google Scholar] - Mejias, L., Diguet, J. P., Dezan, C., Campbell, D., Kok, J., & Coppin, G. (2021). Embedded computation architectures for autonomy in unmanned aircraft systems (UAS). Sensors, 21(4), 1115.
[CrossRef] [Google Scholar] - Partheepan, S., Sanati, F., & Hassan, J. (2023). Autonomous unmanned aerial vehicles in bushfire management: Challenges and opportunities. Drones, 7(1), 47.
[CrossRef] [Google Scholar] - Floreano, D., & Wood, R. J. (2015). Science, technology and the future of small autonomous drones. nature, 521(7553), 460-466.
[CrossRef] [Google Scholar] - Wu, P., Li, Y., & Xue, D. (2025). UAV target tracking: A survey. Artificial Intelligence Review, 58(11), 358.
[CrossRef] [Google Scholar] - Sun, N., Zhao, J., Shi, Q., Liu, C., & Liu, P. (2024). Moving target tracking by unmanned aerial vehicle: A survey and taxonomy. IEEE Transactions on Industrial Informatics, 20(5), 7056-7068.
[CrossRef] [Google Scholar] - Alhafnawi, M., Salameh, H. A. B., Masadeh, A. E., Al-Obiedollah, H., Ayyash, M., El-Khazali, R., & Elgala, H. (2023). A survey of indoor and outdoor uav-based target tracking systems: Current status, challenges, technologies, and future directions. IEEE Access, 11, 68324-68339.
[CrossRef] [Google Scholar] - Wang, X., Sun, Z., Chehri, A., Jeon, G., & Song, Y. (2024). Deep learning and multi-modal fusion for real-time multi-object tracking: Algorithms, challenges, datasets, and comparative study. Information Fusion, 105, 102247.
[CrossRef] [Google Scholar] - Choutri, K., Lagha, M., Meshoul, S., Batouche, M., Kacel, Y., & Mebarkia, N. (2022). A multi-lingual speech recognition-based framework to human-drone interaction. Electronics, 11(12), 1829.
[CrossRef] [Google Scholar] - Domfeh, E. A., & Dancy, C. L. (2025, September). Human-AI use patterns for decision-making in disaster scenarios: A systematic review. In 2025 IEEE International Symposium on Technology and Society (ISTAS) (pp. 1-10). IEEE.
[CrossRef] [Google Scholar] - Debele, Y., Shi, H. Y., Wondosen, A., Ku, T. W., & Kang, B. S. (2023). Deep learning-based robust actuator fault detection and isolation scheme for highly redundant multirotor UAVs. Drones, 7(7), 437.
[CrossRef] [Google Scholar] - Zhao, H., Xia, T., Xia, Y., Yang, J., Liu, M., & Zhu, H. (2025). Safe and saving: A joint learning and energy-efficient scheduling scheme of UAV assisted hierarchical federated learning for remote inspection within large scale IIoT. IEEE Internet of Things Journal, 12(13), 25357-25370.
[CrossRef] [Google Scholar] - Wang, M., Wang, Q., Wang, Z., Gao, Y., Wang, J., Cui, C., ... & Gao, F. (2025). Unlocking aerobatic potential of quadcopters: Autonomous freestyle flight generation and execution. Science robotics, 10(101), eadp9905.
[CrossRef] [Google Scholar] - Lu, J., Zhang, X., Shen, H., Xu, L., & Tian, B. (2024). You only plan once: A learning-based one-stage planner with guidance learning. IEEE Robotics and Automation Letters, 9(7), 6083-6090.
[CrossRef] [Google Scholar] - Zheng, X., Sun, G., Li, J., Wang, J., Wu, Q., Niyato, D., & Jamalipour, A. (2025). UAV swarm-enabled collaborative post-disaster communications in low altitude economy via a two-stage optimization approach. IEEE Transactions on Mobile Computing, 24(11), 11833-11851.
[CrossRef] [Google Scholar] - Wang, Y., Wang, Z., Cheng, P., Tian, P., Yuan, Z., Tian, J., Wang, W., & Zhao, L. (2025). AVCPNet: An AAV-vehicle collaborative perception network for 3-D object detection. IEEE Transactions on Geoscience and Remote Sensing, 63, 1-16.
[CrossRef] [Google Scholar] - Zhou, B., Xu, H., & Shen, S. (2023). Racer: Rapid collaborative exploration with a decentralized multi-uav system. IEEE Transactions on Robotics, 39(3), 1816-1835.
[CrossRef] [Google Scholar] - Chen, X., Xiao, Z., Cheng, Y., Hsia, C., Wang, H., Xu, J., Xu, S., Dang, F., Zhang, X., Liu, Y., & Chen, X. (2024). SOScheduler: Toward Proactive and Adaptive Wildfire Suppression via Multi-UAV Collaborative Scheduling. IEEE Internet of Things Journal, 11(14), 24858-24871.
[CrossRef] [Google Scholar] - Cao, H., Shen, J., Zhang, Y., Fu, Z., Liu, C., Sun, S., & Zhao, S. (2025). Proximal cooperative aerial manipulation with vertically stacked drones. Nature, 646(8085), 576-583.
[CrossRef] [Google Scholar] - Li, T., Liu, J., Zhang, W., Ni, Y., Wang, W., & Li, Z. (2021, June). Uav-human: A large benchmark for human behavior understanding with unmanned aerial vehicles. In 2021 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR) (pp. 16261-16270). IEEE.
[CrossRef] [Google Scholar] - Sharma, S., & Chakravarti, D. (2005). UAV operations: An analysis of incidents and accidents with human factors and crew resource management perspective. Indian Journal of Aerospace Medicine, 49(1), 29-36. https://indjaerospacemed.com/uav-operations-an-analysis-of-incidents-and-accidents-with-human-factors-and-crew-resource-management-perspective/
[Google Scholar] - Adil, M., Song, H., Mastorakis, S., Abulkasim, H., Farouk, A., & Jin, Z. (2023). UAV-assisted IoT applications, cybersecurity threats, AI-enabled solutions, open challenges with future research directions. IEEE Transactions on Intelligent Vehicles, 9(4), 4583-4605.
[CrossRef] [Google Scholar] - Hadi, H. J., Cao, Y., Nisa, K. U., Jamil, A. M., & Ni, Q. (2023). A comprehensive survey on security, privacy issues and emerging defence technologies for UAVs. Journal of Network and Computer Applications, 213, 103607.
[CrossRef] [Google Scholar] - Hassler, S. C., Mughal, U. A., & Ismail, M. (2023). Cyber-physical intrusion detection system for unmanned aerial vehicles. IEEE Transactions on Intelligent Transportation Systems, 25(6), 6106-6117.
[CrossRef] [Google Scholar] - Liu, K., & Zheng, J. (2022). UAV trajectory optimization for time-constrained data collection in UAV-enabled environmental monitoring systems. IEEE Internet of Things Journal, 9(23), 24300-24314.
[CrossRef] [Google Scholar] - Ismail, N., Mohd Kamal, N. L., Norhashim, N., Abdul Hamid, S., Sahwee, Z., & Ahmad Shah, S. (2025). Electric Propulsion and Hybrid Energy Systems for Solar-Powered UAVs: Recent Advances and Challenges. Drones, 9(12), 846.
[CrossRef] [Google Scholar] - Wu, J., Wang, H., Huang, Y., Su, Z., & Zhang, M. (2018). Energy management strategy for solar-powered UAV long-endurance target tracking. IEEE transactions on aerospace and electronic systems, 55(4), 1878-1891.
[CrossRef] [Google Scholar] - Wang, X., Yang, D., Liao, Y., Zheng, W., Dai, B., Li, H., & Liu, S. (2026). UAV-Flow Colosseo: A real-world benchmark for flying-on-a-word UAV imitation learning. Advances in Neural Information Processing Systems, 38.
[Google Scholar] - Vaščák, J., Mikčo, P., Papcun, P., Urblík, Ľ., & Zolotová, I. (2025, November). Use of augmented reality concept for UAV simulation. In 2025 International Conference on Emerging eLearning Technologies and Applications (ICETA) (pp. 853-858). IEEE.
[CrossRef] [Google Scholar] - Liu, H., Bi, Z., Dai, J., Yu, Y., & Shi, Y. (2018, October). UAV simulation flight training system. In 2018 International Conference on Virtual Reality and Visualization (ICVRV) (pp. 150-151). IEEE.
[CrossRef] [Google Scholar] - Torens, C., Juenger, F., Schirmer, S., Schopferer, S., Zhukov, D., & Dauer, J. C. (2023). Ensuring safety of machine learning components using operational design domain. In AIAA SciTech 2023 Forum (p. 1124).
[CrossRef] [Google Scholar] - U.S. Air Force Research Laboratory. (2024). USAF Test Pilot School and DARPA announce breakthrough in aerospace machine learning. U.S. Air Force Research Laboratory. Retrieved from https://www.afrl.af.mil/News/Article-Display/Article/3745032/usaf-test-pilot-school-and-darpa-announce-breakthrough-in-aerospace-machine-lea/
[Google Scholar] - Baykar. (2025). Bayraktar Kizilelma performs formation flight using smart fleet autonomy. Baykar Technologies. Retrieved from https://baykartech.com/en/press/bayraktar-kizilelma-performs-formation-flight-using-smart-fleet-autonomy/
[Google Scholar] - Airbus. (2024). Airbus and European partners demonstrate collaboration between helicopters and unmanned systems. Airbus Newsroom. Retrieved from https://www.airbus.com/en/newsroom/press-releases/2024-10-airbus-and-european-partners-demonstrate-collaboration-between
[Google Scholar] - Harmattan AI. (n.d.). GOBI high-speed drone interceptor. Harmattan AI. Retrieved from https://harmattan.ai/systems/gobi
[Google Scholar] - Bae, K. B., Park, J. H., & Park, S. O. (2024, November). Detection of UAV in a Clutter Environment using Pulse Doppler Radar. In 2024 International Symposium on Antennas and Propagation (ISAP) (pp. 1-2). IEEE.
[CrossRef] [Google Scholar] - Agrawal, J., & Arafat, M. Y. (2024). Transforming farming: A review of AI-powered UAV technologies in precision agriculture. Drones, 8(11), 664.
[CrossRef] [Google Scholar] - Hou, P., Huang, Y., Zhu, H., Lu, Z., Huang, S. C., Yang, Y., & Chai, H. (2024). Distributed DRL-based integrated sensing, communication, and computation in cooperative UAV-enabled intelligent transportation systems. IEEE Internet of Things Journal, 12(5), 5792-5806.
[CrossRef] [Google Scholar] - Scherer, J., Yahyanejad, S., Hayat, S., Yanmaz, E., Andre, T., Khan, A., ... & Rinner, B. (2015, May). An autonomous multi-UAV system for search and rescue. In Proceedings of the first workshop on micro aerial vehicle networks, systems, and applications for civilian use (pp. 33-38).
[CrossRef] [Google Scholar] - Ma, S., Zhang, Y., Peng, L., Sun, C., Ding, B., & Zhu, Y. (2025). OWRT-DETR: A novel real-time transformer network for small-object detection in open-water search and rescue from UAV aerial imagery. IEEE Transactions on Geoscience and Remote Sensing, 63, 1-13.
[CrossRef] [Google Scholar] - Xing, L., Fan, X., Dong, Y., Xiong, Z., Xing, L., Yang, Y., ... & Zhou, C. (2022). Multi-UAV cooperative system for search and rescue based on YOLOv5. International Journal of Disaster Risk Reduction, 76, 102972.
[CrossRef] [Google Scholar] - Tsouros, D. C., Bibi, S., & Sarigiannidis, P. G. (2019). A review on UAV-based applications for precision agriculture. Information, 10(11), 349.
[CrossRef] [Google Scholar] - Nisingizwe, M. P., Ndishimye, P., Swaibu, K., Nshimiyimana, L., Karame, P., Dushimiyimana, V., ... & Law, M. R. (2022). Effect of unmanned aerial vehicle (drone) delivery on blood product delivery time and wastage in Rwanda: a retrospective, cross-sectional study and time series analysis. The Lancet Global Health, 10(4), e564-e569.
[CrossRef] [Google Scholar] - Bibbò, L., Laganà, F., Bilotta, G., Meduri, G. M., Angiulli, G., & Cotroneo, F. (2025). AI-enhanced eco-efficient UAV design for sustainable urban logistics: integration of embedded intelligence and renewable energy systems. Energies, 18(19), 5242.
[CrossRef] [Google Scholar] - Li, S., & Qin, W. (2025, August). Optimization of UAV Distribution Route under Carbon Tax Constraints--An Empirical Study of Hankou North Based on Improved Grey Wolf Algorithm. In Proceedings of the 2nd International Conference on Intelligent Computing and Data Analysis (pp. 644-650).
[CrossRef] [Google Scholar] - Jahan, I., Mehana, M., Matheou, G., & Viswanathan, H. (2024). Deep Learning-Based quantifications of methane emissions with field applications. International Journal of Applied Earth Observation and Geoinformation, 132, 104018.
[CrossRef] [Google Scholar] - Heo, S. J., & Na, W. S. (2025). Review of drone-based technologies for wind turbine blade inspection. Electronics, 14(2), 227.
[CrossRef] [Google Scholar] - Mirzabeigi, S., Razkenari, R., & Crovella, P. (2025). A review of the potential of drone-based approaches for integrated building envelope assessment. Buildings, 15(13), 2230.
[CrossRef] [Google Scholar] - Sharma, S., Dhal, S., Rout, T., & Acharya, B. S. (2022). Drones and machine learning for estimating forest carbon storage. Carbon Research, 1(1), 21.
[CrossRef] [Google Scholar] - Wei, W., & Li, J. (2025). Assessing the three-dimensional vegetation carbon sink of urban green spaces using unmanned aerial vehicles and machine learning. Ecological Indicators, 173, 113380.
[CrossRef] [Google Scholar] - Civil Aviation Administration of China (CAAC). (2022, January 21). Notice of the Civil Aviation Administration of China on issuing the Smart Civil Aviation Construction Roadmap [Government Policy Document, Document No.: Minhang Fa(2022)No. 1]. http://www.caacnews.com.cn/1/1/202201/P020220121491747678948.pdf
[Google Scholar] - Krupáš, M., Urblík, Ľ., & Zolotová, I. (2025). Multimodal AI for UAV: Vision-language models in human-machine collaboration. Electronics, 14(17), 3548.
[CrossRef] [Google Scholar] - Ali, H., Pham, D. T., Alam, S., Schultz, M., Li, M. Z., Wang, Y., ... & Duong, V. N. (2025). Human-AI hybrids in safety-critical systems: concept, definition and perspectives from air traffic management. Advanced Engineering Informatics, 65, 103256.
[CrossRef] [Google Scholar] - Xie, R., He, H., Meng, X., & Fan, X. (2023). Neural-network-based dynamic flight envelop protection within integrated aircraft control system. Journal of Guidance, Control, and Dynamics, 46(6), 1083-1094.
[CrossRef] [Google Scholar] - Yue, T., Wang, X., Wang, B., Tai, S., Liu, H., Wang, L., & Jiang, F. (2025). Design of ice tolerance flight envelope protection control system for uav based on lstm neural network for detecting icing severity. Drones, 9(1), 63.
[CrossRef] [Google Scholar] - Priya, S. S., Sanjana, P. S., Yanamala, R. M. R., Amar Raj, R. D., Pallakonda, A., Napoli, C., & Randieri, C. (2025). Flight-safe inference: SVD-compressed LSTM acceleration for real-time UAV engine monitoring using custom FPGA hardware architecture. Drones, 9(7), 494.
[CrossRef] [Google Scholar] - European Union Aviation Safety Agency (EASA). (2023). EASA concept paper: Guidance for Level 1 & 2 machine learning applications, proposed Issue~02 [Regulatory guidance document]. EASA. Retrieved from https://www.easa.europa.eu/en/document-library/general-publications/easa-artificial-intelligence-concept-paper-issue-2
[Google Scholar] - Jasra, S. K., Valentino, G., Muscat, A., & Camilleri, R. (2025). A comparative study of unsupervised deep learning methods for anomaly detection in flight data. Aerospace, 12(7), 645.
[CrossRef] [Google Scholar] - Zhao, J., & Lin, X. (2025). General-purpose aerial intelligent agents empowered by large language models. arXiv preprint arXiv:2503.08302.
[CrossRef] [Google Scholar] - Gould, D. S. W., De Ath, G., Carvell, B., & Pepper, N. (2025). AirTrafficGen: Configurable air traffic scenario generation with large language models. arXiv preprint arXiv:2508.02269.
[CrossRef] [Google Scholar] - Larsen, O. F. P., Ruocco, M., Spitieris, M., Murad, A., & Ragosta, M. (2025). Learning to Land Anywhere: Transferable Generative Models for Aircraft Trajectories. arXiv preprint arXiv:2511.04155.
[CrossRef] [Google Scholar] - Zuo, D., Cai, K., Li, M., Zhu, Y., & Zhao, P. (2025). AirTraj-Diff: Generating Aircraft Trajectory With Conditional Diffusion Probabilistic Model. IEEE Transactions on Intelligent Transportation Systems, 26(12), 21667-21683.
[CrossRef] [Google Scholar] - Wang, Y., Sun, G., Sun, Z., Wang, J., Li, J., Zhao, C., Wu, J., Liang, S., Yin, M., Wang, P., Niyato, D., Sun, S., & In Kim, D. (2025). Toward realization of low-altitude economy networks: Core architecture, integrated technologies, and future directions. IEEE Transactions on Cognitive Communications and Networking, 11, 2788-2820.
[CrossRef] [Google Scholar] - Calderón, M., Aguilar, W. G., & Merizalde, D. (2020, May). Visual-based real-time detection using neural networks and micro-uavs for military operations. In International Conference of Research Applied to Defense and Security (pp. 55-64). Singapore: Springer Nature Singapore.
[CrossRef] [Google Scholar] - Lee, C. E., Baek, J., Son, J., & Ha, Y. G. (2023). Deep AI military staff: cooperative battlefield situation awareness for commander's decision making. The Journal of Supercomputing, 79(6), 6040-6069.
[CrossRef] [Google Scholar] - Dos Santos, G. R., Riffel, D. B., Ramos, A. C. B., & Ramos, A. C. R. (2025). Bio-inspired drone swarms for target neutralization using intelligent munitions. IEEE Access, 13, 190221-190237.
[CrossRef] [Google Scholar] - Stöcker, C., Bennett, R., Nex, F., Gerke, M., & Zevenbergen, J. (2017). Review of the current state of UAV regulations. Remote sensing, 9(5), 459.
[CrossRef] [Google Scholar] - Lee, D., Hess, D. J., & Heldeweg, M. A. (2022). Safety and privacy regulations for unmanned aerial vehicles: A multiple comparative analysis. Technology in Society, 71, 102079.
[CrossRef] [Google Scholar] - Mukkamala, R., Aljohani, M., Rangi, A., & Olariu, S. (2023, October). Enhancing security, privacy, and trust in connected uav systems. In 2023 IEEE/AIAA 42nd Digital Avionics Systems Conference (DASC) (pp. 1-10). IEEE.
[CrossRef] [Google Scholar] - Chen, X., & Yan, R. (2025). Tripartite evolutionary game analysis of UAV technology investment and application under government incentives: Based on the low-altitude economic background. 14th International Conference on Logistics and Systems Engineering (ICLSE 2024).
[CrossRef] [Google Scholar] - Halaby, M., Pho Duc, C., Hutchinson, C., & Marrinan, B. (2022). Financing aviation decarbonisation. In ICAO environmental report 2022 (pp. 38–40). International Civil Aviation Organization. https://www.icao.int/sites/default/files/environmental-protection/Documents/EnvironmentalReports/2022/ENVReport2022_Art9.pdf
[Google Scholar] - Gomes, S., Lopes, J. M., & Sousa, B. B. (2025). Delivering tomorrow today: The role of cutting-edge technologies such as Artificial Intelligence in drones in shaping new business models. Research in Transportation Business & Management, 60, 101365.
[CrossRef] [Google Scholar] - Jahani, H., Khosravi, Y., Kargar, B., Ong, K. L., & Arisian, S. (2025). Exploring the role of drones and UAVs in logistics and supply chain management: a novel text-based literature review. International Journal of Production Research, 63(5), 1873-1897.
[CrossRef] [Google Scholar] - Eskandaripour, H., & Boldsaikhan, E. (2023). Last-mile drone delivery: Past, present, and future. Drones, 7(2), 77.
[CrossRef] [Google Scholar] - Kadia, H. (2025, October 3). Stakeholder collaboration in aviation: Why connectivity must extend across the ecosystem [Web report]. Tecknexus. Retrieved from https://tecknexus.com/stakeholder-collaboration-in-aviation-why-connectivity-must-extend-across-the-ecosystem/
[Google Scholar] - Perez-Cerrolaza, J., Abella, J., Borg, M., Donzella, C., Cerquides, J., Cazorla, F. J., ... & Flores, J. L. (2024). Artificial intelligence for safety-critical systems in industrial and transportation domains: A survey. ACM Computing Surveys, 56(7), 1-40.
[CrossRef] [Google Scholar] - Henderson, A., Harbour, S., & Cohen, K. (2022, September). Toward airworthiness certification for artificial intelligence (AI) in aerospace systems. In 2022 IEEE/AIAA 41st Digital Avionics Systems Conference (DASC) (pp. 1-10). IEEE.
[CrossRef] [Google Scholar] - Bello, H., Geißler, D., Ray, L., Müller-Divéky, S., Müller, P., Kittrell, S., ... & Lukowicz, P. (2024). Towards certifiable AI in aviation: landscape, challenges, and opportunities. arXiv preprint arXiv:2409.08666.
[CrossRef] [Google Scholar] - Khaneghaei, M., Asadi, D., Ebrahimi, B., Hazeri, M., Farsadi, T., Nabavi Chashmi, Y., & Durhasan, T. (2026). A unified and experimentally validated design framework for long-endurance solar UAVS using model-based multi-objective multidisciplinary optimization. Structural and Multidisciplinary Optimization, 69(1), 3.
[CrossRef] [Google Scholar] - Martins, J. R., & Lambe, A. B. (2013). Multidisciplinary design optimization: a survey of architectures. AIAA journal, 51(9), 2049-2075.
[CrossRef] [Google Scholar] - Papageorgiou, A., Tarkian, M., Amadori, K., & Ölvander, J. (2018). Multidisciplinary design optimization of aerial vehicles: A review of recent advancements. International Journal of Aerospace Engineering, 2018(1), 4258020.
[CrossRef] [Google Scholar]
Cite This Article
TY  - JOUR
AU  - Liu, Zenglin
AU  - Wang, Yubo
AU  - Yim, Pascal
PY  - 2026
DA  - 2026/09/22
TI  - Artificial Intelligence in Aerial Unmanned Systems: A Comprehensive Review of Evolution, Applications, and Future Trends
JO  - Journal of Carbon Neutrality
T2  - Journal of Carbon Neutrality
JF  - Journal of Carbon Neutrality
VL  - 1
IS  - 2
SP  - 127
EP  - 154
DO  - 10.62762/JCN.2026.328644
UR  - https://www.icck.org/article/abs/JCN.2026.328644
KW  - aerial unmanned systems
KW  - unmanned aerial vehicle (UAV)
KW  - artificial intelligence (AI)
KW  - carbon neutrality
KW  - low-carbon aviation
KW  - green aviation
KW  - sustainable development
KW  - development trends
KW  - swarm intelligence
AB  - Achieving carbon neutrality in the aviation sector demands transformative technologies, and Artificial Intelligence (AI)-enabled aerial unmanned systems are emerging as a critical enabler of low-carbon flight operations, environmental monitoring, and sustainable airspace governance, yet a comprehensive synthesis that jointly addresses their technical architecture, climate-oriented applications, and regulatory pathways remains limited. This review provides a systematic analysis of AI-enabled aerial unmanned systems using a structured literature review framework aligned with PRISMA principles. We first summarize the evolution and classification of aerial unmanned platforms, then propose a layered technical perspective covering perception, decision-making, control, collaboration, and support capabilities. On this basis, we map representative advances in military and civilian scenarios, including autonomous navigation, multi-UAV cooperation, infrastructure inspection, emergency response, and logistics operations. A dedicated discussion further examines AI-driven decarbonization pathways, showing how intelligent energy management and trajectory optimization, together with UAV-based environmental sensing, can contribute to low-carbon aviation and climate-oriented operations. We also identify major barriers to large-scale deployment, including robustness in complex environments, edge intelligence constraints, explainability and trust, cybersecurity, regulatory compliance, and interdisciplinary talent gaps. Finally, we outline future directions centered on embodied intelligence, stronger onboard computing, swarm-level autonomy, and internationally harmonized standards. This review offers an integrated roadmap for researchers, engineers, and policymakers to advance safe, scalable, and sustainable AI-enabled unmanned aviation.
SN  - 3144-2668
PB  - Institute of Central Computation and Knowledge
LA  - English
ER  -
@article{Liu2026Artificial,
  author = {Zenglin Liu and Yubo Wang and Pascal Yim},
  title = {Artificial Intelligence in Aerial Unmanned Systems: A Comprehensive Review of Evolution, Applications, and Future Trends},
  journal = {Journal of Carbon Neutrality},
  year = {2026},
  volume = {1},
  number = {2},
  pages = {127-154},
  doi = {10.62762/JCN.2026.328644},
  url = {https://www.icck.org/article/abs/JCN.2026.328644},
  abstract = {Achieving carbon neutrality in the aviation sector demands transformative technologies, and Artificial Intelligence (AI)-enabled aerial unmanned systems are emerging as a critical enabler of low-carbon flight operations, environmental monitoring, and sustainable airspace governance, yet a comprehensive synthesis that jointly addresses their technical architecture, climate-oriented applications, and regulatory pathways remains limited. This review provides a systematic analysis of AI-enabled aerial unmanned systems using a structured literature review framework aligned with PRISMA principles. We first summarize the evolution and classification of aerial unmanned platforms, then propose a layered technical perspective covering perception, decision-making, control, collaboration, and support capabilities. On this basis, we map representative advances in military and civilian scenarios, including autonomous navigation, multi-UAV cooperation, infrastructure inspection, emergency response, and logistics operations. A dedicated discussion further examines AI-driven decarbonization pathways, showing how intelligent energy management and trajectory optimization, together with UAV-based environmental sensing, can contribute to low-carbon aviation and climate-oriented operations. We also identify major barriers to large-scale deployment, including robustness in complex environments, edge intelligence constraints, explainability and trust, cybersecurity, regulatory compliance, and interdisciplinary talent gaps. Finally, we outline future directions centered on embodied intelligence, stronger onboard computing, swarm-level autonomy, and internationally harmonized standards. This review offers an integrated roadmap for researchers, engineers, and policymakers to advance safe, scalable, and sustainable AI-enabled unmanned aviation.},
  keywords = {aerial unmanned systems, unmanned aerial vehicle (UAV), artificial intelligence (AI), carbon neutrality, low-carbon aviation, green aviation, sustainable development, development trends, swarm intelligence},
  issn = {3144-2668},
  publisher = {Institute of Central Computation and Knowledge}
}
Article Metrics
Publisher's Note
ICCK stays neutral with regard to jurisdictional claims in published maps and institutional affiliations.
Rights and Permissions
 Copyright © 2026 by the Author(s). Published by Institute of Central Computation and Knowledge. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/), which permits use, sharing, adaptation, distribution and reproduction in any medium or format, as long as you give appropriate credit to the original author(s) and the source, provide a link to the Creative Commons licence, and indicate if changes were made.