Investigation on the Mechanism of Nebulized Droplet Particle Size Impact in Precision Plant Protection

Article Information
Abstract
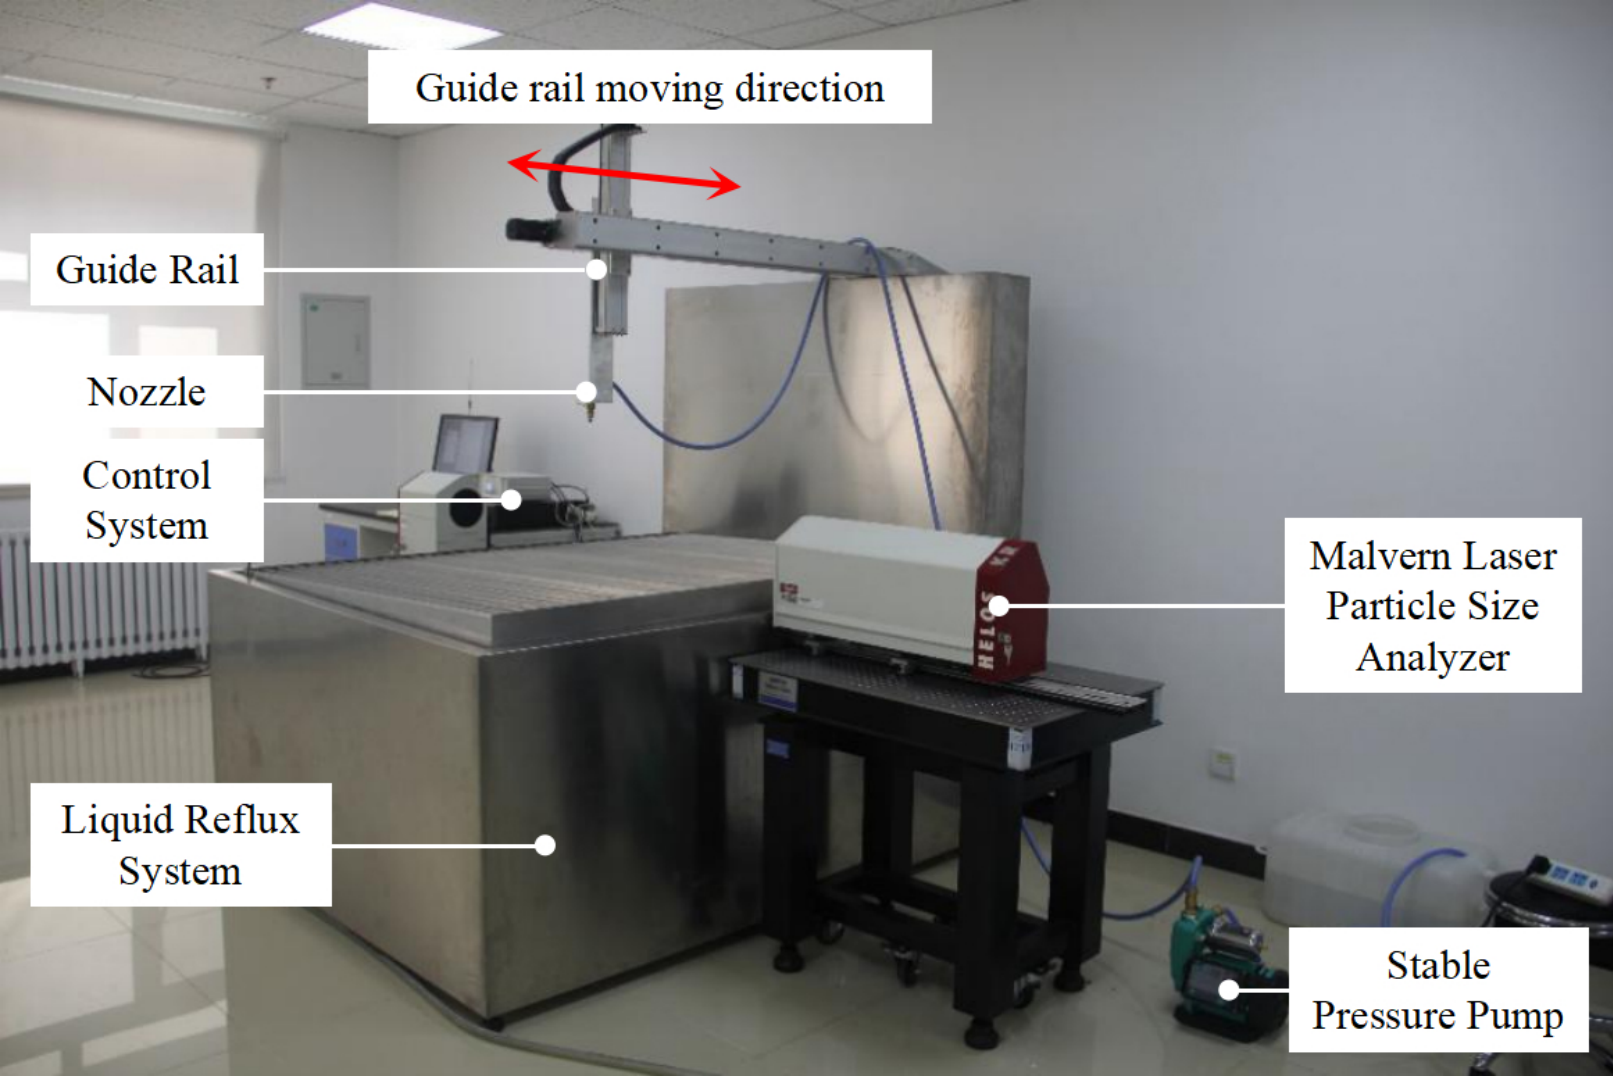
This paper presents an AI-driven intelligent control system for precision spray applications that integrates real-time perception, neural network prediction, reinforcement learning optimization, and online Bayesian learning. A two-tier architecture is established: Tier 1 employs neural network-based feedback control for rapid pressure adjustment (0.1–0.3 MPa), while Tier 2 deploys an RL agent for optimal nozzle selection when pressure control is insufficient. The neural network model achieves high prediction accuracy with an RMSE of 3.2 $\mu$m on the test set. The RL agent demonstrates effective decision-making, attaining a 94.5% success rate in simulation and closed-loop experiments for maintaining target droplet size within $\pm$10 $\mu$m. Online Bayesian updates improve prediction accuracy by an average of 8.7% after every 100 field observations. Experimental validation demonstrates autonomous optimization, rapid convergence (3–5 cycles), and continuous learning without human retraining, offering a fully autonomous solution suitable for UAV deployment and precision agriculture.
Graphical Abstract
Keywords
Data Availability Statement
Funding
Conflicts of Interest
Ethical Approval and Consent to Participate
References
- Chen, C., Li, S., Wu, X., Li, J., Jia, Y., Kang, F., & Wang, Y. (2023). Research on the deposition law of the spray droplet group based on single droplet multiphase flow simulation. Journal of Cleaner Production, 423, 138605.
[CrossRef] [Google Scholar] - Zhu, W., & Wang, R. (2021). Impact of farm size on intensity of pesticide use: Evidence from China. Science of the total environment, 753, 141696.
[CrossRef] [Google Scholar] - Dorman, R. G. (1952). The atomization of liquid in a flat spray. British journal of applied physics, 3(6), 189-192.
[CrossRef] [Google Scholar] - Dombrowski, N., & Foumeny, E. A. (1998). On the stability of liquid sheets in hot atmospheres. Atomization and Sprays, 8(2).
[CrossRef] [Google Scholar] - Post, S. L., & Hewitt, A. J. (2018). Flat-fan spray atomization model. Transactions of the ASABE, 61(4), 1249-1256.
[CrossRef] [Google Scholar] - Liao, J., Luo, X., Wang, P., Zhou, Z., O’Donnell, C. C., Zang, Y., & Hewitt, A. J. (2020). Analysis of the influence of different parameters on droplet characteristics and droplet size classification categories for air induction nozzle. Agronomy, 10(2), 256.
[CrossRef] [Google Scholar] - Musiu, E. M., Qi, L., & Wu, Y. (2019). Evaluation of droplets size distribution and velocity pattern using Computational Fluid Dynamics modelling. Computers and Electronics in Agriculture, 164, 104886.
[CrossRef] [Google Scholar] - Rogers, H., De La Iglesia, B., Zebin, T., Cielniak, G., & Magri, B. (2024). Advancing precision agriculture: domain-specific augmentations and robustness testing for convolutional neural networks in precision spraying evaluation. Neural Computing and Applications, 36(32), 20211-20229.
[CrossRef] [Google Scholar] - Huang, Y. Y., Li, Z. W., Yang, C. H., & Huang, Y. M. (2023). Automatic path planning for spraying drones based on deep q-learning. Journal of Internet Technology, 24(3), 565-575.
[CrossRef] [Google Scholar] - Sun, F., Wang, X., & Zhang, R. (2021). Improved Q-learning algorithm based on approximate state matching in agricultural plant protection environment. Entropy, 23(6), 737.
[CrossRef] [Google Scholar] - Joyce Jr, W. H., & Luxhøj, C. A. (2017). Modeling multiple UAS performing agricultural spraying: object-oriented Bayesian network approach. In IISE Annual Conference. Proceedings (pp. 410-415). Institute of Industrial and Systems Engineers (IISE). https://www.proquest.com/openview/4815c2f6ae4a5b3a95ce6cd4e0fa1a3d/1?pq-origsite=gscholar&cbl=51908
[Google Scholar] - Zhang, Z., Wang, X., Lai, Q., & Zhang, Z. (2018). Review of variable-rate sprayer applications based on real-time sensor technologies. Automation in Agriculture-Securing Food Supplies for Future Generations, 13, 13-25.
[CrossRef] [Google Scholar] - Tate, R. W. (1961). Immersion sampling of spray droplets. AIChE Journal, 7(4), 574-577.
[CrossRef] [Google Scholar] - Kooij, S., Sijs, R., Denn, M. M., Villermaux, E., & Bonn, D. (2018). What determines the drop size in sprays?. Physical review X, 8(3), 031019.
[CrossRef] [Google Scholar] - Wen, S., Zhang, Q., Yin, X., Lan, Y., Zhang, J., & Ge, Y. (2019). Design of plant protection UAV variable spray system based on neural networks. Sensors, 19(5), 1112.
[CrossRef] [Google Scholar] - Cieniawska, B., Pentoś, K., & Łuczycka, D. (2020). Neural modeling and optimization of the coverage of the sprayed surface. Bulletin of the Polish Academy of Sciences: Technical Sciences.
[CrossRef] [Google Scholar] - Hanif, A. S., Han, X., Yu, S. H., Han, C., Baek, S. W., Lee, C. G., ... & Kang, Y. H. (2023). Modeling of the control logic of a UASS based on coefficient of variation spraying distribution analysis in an indoor flight simulator. Frontiers in Plant Science, 14, 1235548.
[CrossRef] [Google Scholar] - Acharya, P., Burgers, T., & Nguyen, K. D. (2023). A deep-learning framework for spray pattern segmentation and estimation in agricultural spraying systems. Scientific Reports, 13(1), 7545.
[CrossRef] [Google Scholar] - Hao, Z., Li, X., Meng, C., Yang, W., & Li, M. (2022). Adaptive spraying decision system for plant protection unmanned aerial vehicle based on reinforcement learning. International Journal of Agricultural and Biological Engineering, 15(4), 16-26. https://dx.doi.org/10.25165/j.ijabe.20221504.6929
[Google Scholar] - Xue, X., Tian, Y., Yang, Z., Li, Z., Lyu, S., Song, S., & Sun, D. (2024). Research on a UAV spray system combined with grid atomized droplets. Frontiers in Plant Science, 14, 1286332.
[CrossRef] [Google Scholar] - Lefebvre, A. H., & McDonell, V. G. (2017). Atomization and sprays. CRC press.
[CrossRef] [Google Scholar] - Ohnesorge, W. von. (2019). The formation of drops by nozzles and the breakup of liquid jets. University of Texas at Austin.
[CrossRef] [Google Scholar] - York, J. L., Stubbs, H. E., & Tek, M. R. (1953). The mechanism of disintegration of liquid sheets. Transactions of the American society of Mechanical Engineers, 75(7), 1279-1286.
[CrossRef] [Google Scholar] - Squire, H. Á. (1953). Investigation of the instability of a moving liquid film. British Journal of applied physics, 4(6), 167-169.
[CrossRef] [Google Scholar]
Cited By (4)
-
Yantong Chen, Yuan Gao, Junsheng Wang. Identification method for multiple similar crop pests: A visual language model combined with coarse–finegrain cross‐modal matching.
Pest Management Science, 2026 , 82 (7).
[CrossRef] -
N. M. Deepika, K. Sreeama Murthy. AgroAttenNet: A CNN–BiLSTM–Attention–Random Forest Hybrid Model for Temporal Groundnut Yield Forecasting.
Journal of Advances in Information Technology, 2026 , 17 (4).
[CrossRef] -
Banghong Wu, Yang Cao, Jing Yang, Jiheng Wu. AR-FRSG: Fine-grained agricultural image recognition via feature space reconstruction and semantically guided fusion.
Expert Systems with Applications, 2026 , 316 .
[CrossRef] -
Jianlei Kong, Shunong Tang, Jiameng Feng, Lipo Mo, Xuebo Jin. AASNet: A Novel Image Instance Segmentation Framework for Fine-Grained Fish Recognition via Linear Correlation Attention and Dynamic Adaptive Focal Loss.
Applied Sciences, 2025 , 15 (7).
[CrossRef]
Cite This Article
TY  - JOUR
AU  - Ma, Hui
AU  - Tang, Jiajia
AU  - Lv, Huimin
AU  - Chu, Wenyan
AU  - Sun, Shengdi
PY  - 2024
DA  - 2024/09/29
TI  - Investigation on the Mechanism of Nebulized Droplet Particle Size Impact in Precision Plant Protection
JO  - ICCK Transactions on Intelligent Systematics
T2  - ICCK Transactions on Intelligent Systematics
JF  - ICCK Transactions on Intelligent Systematics
VL  - 1
IS  - 2
SP  - 102
EP  - 111
DO  - 10.62762/TIS.2024.307219
UR  - https://www.icck.org/article/abs/tis.2024.307219
KW  - neural networks
KW  - reinforcement learning
KW  - intelligent control
KW  - real-time optimization
KW  - autonomous systems
KW  - precision agriculture
AB  - This paper presents an AI-driven intelligent control system for precision spray applications that integrates real-time perception, neural network prediction, reinforcement learning optimization, and online Bayesian learning. A two-tier architecture is established: Tier 1 employs neural network-based feedback control for rapid pressure adjustment (0.1–0.3 MPa), while Tier 2 deploys an RL agent for optimal nozzle selection when pressure control is insufficient. The neural network model achieves high prediction accuracy with an RMSE of 3.2 $\mu$m on the test set. The RL agent demonstrates effective decision-making, attaining a 94.5% success rate in simulation and closed-loop experiments for maintaining target droplet size within $\pm$10 $\mu$m. Online Bayesian updates improve prediction accuracy by an average of 8.7% after every 100 field observations. Experimental validation demonstrates autonomous optimization, rapid convergence (3–5 cycles), and continuous learning without human retraining, offering a fully autonomous solution suitable for UAV deployment and precision agriculture.
SN  - 3068-5079
PB  - Institute of Central Computation and Knowledge
LA  - English
ER  -
@article{Ma2024Investigat,
  author = {Hui Ma and Jiajia Tang and Huimin Lv and Wenyan Chu and Shengdi Sun},
  title = {Investigation on the Mechanism of Nebulized Droplet Particle Size Impact in Precision Plant Protection},
  journal = {ICCK Transactions on Intelligent Systematics},
  year = {2024},
  volume = {1},
  number = {2},
  pages = {102-111},
  doi = {10.62762/TIS.2024.307219},
  url = {https://www.icck.org/article/abs/tis.2024.307219},
  abstract = {This paper presents an AI-driven intelligent control system for precision spray applications that integrates real-time perception, neural network prediction, reinforcement learning optimization, and online Bayesian learning. A two-tier architecture is established: Tier 1 employs neural network-based feedback control for rapid pressure adjustment (0.1–0.3 MPa), while Tier 2 deploys an RL agent for optimal nozzle selection when pressure control is insufficient. The neural network model achieves high prediction accuracy with an RMSE of 3.2 \$\mu\$m on the test set. The RL agent demonstrates effective decision-making, attaining a 94.5\% success rate in simulation and closed-loop experiments for maintaining target droplet size within \$\pm\$10 \$\mu\$m. Online Bayesian updates improve prediction accuracy by an average of 8.7\% after every 100 field observations. Experimental validation demonstrates autonomous optimization, rapid convergence (3–5 cycles), and continuous learning without human retraining, offering a fully autonomous solution suitable for UAV deployment and precision agriculture.},
  keywords = {neural networks, reinforcement learning, intelligent control, real-time optimization, autonomous systems, precision agriculture},
  issn = {3068-5079},
  publisher = {Institute of Central Computation and Knowledge}
}
Publisher's Note
ICCK stays neutral with regard to jurisdictional claims in published maps and institutional affiliations.
Rights and Permissions
Portico