Fixed-Time Adaptive Optimal Parameter Estimation Subject to Dead-Zone and Control of Servo Systems

Article Information
Abstract
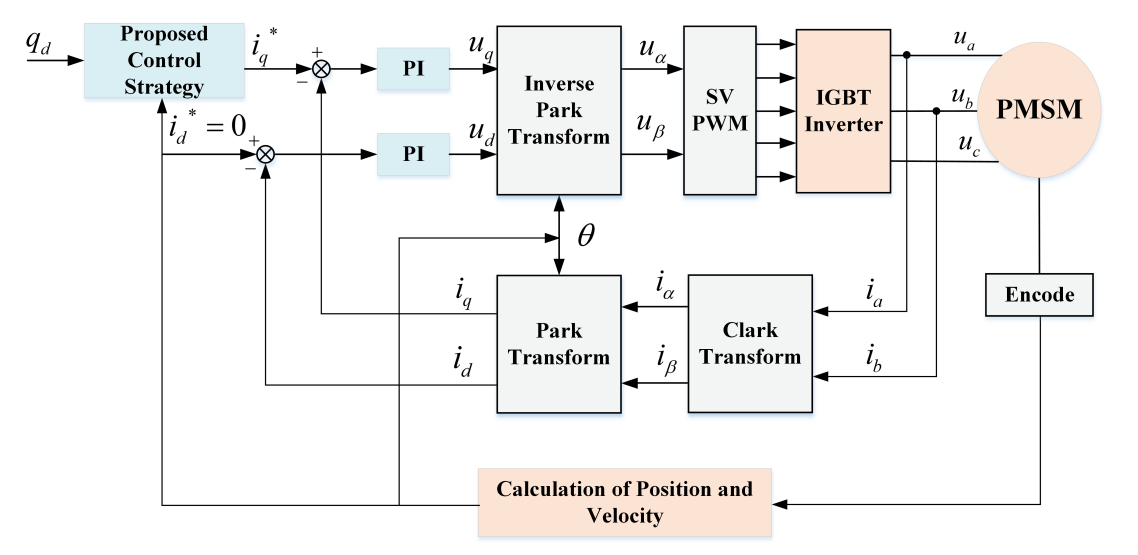
A fixed-time adaptive optimal parameter estimation (FxT-AOPE) scheme is proposed to address the difficulties in estimating dead zone parameters and slow convergence speed of tracking errors in permanent magnet synchronous motor systems. First, the continuous piecewise linear neural network is used to model the nonlinear dead zone dynamics. Second, an auxiliary filter is constructed to extract estimation errors, and this filter is used to drive an adaptive law with time-varying gain, minimizing the cost function of estimation errors and achieving adaptive optimal parameter estimation (AOPE). Then, the AOPE method is introduced into the fixed-time non-singular terminal sliding mode control (FxT-NTSMC) of the permanent magnet synchronous motor system, and the FxT-AOPE strategy is proposed to ensure the fixed-time convergence of estimation error and tracking error. The stability of the closed-loop system is analyzed using Lyapunov stability theory. Finally, the feasibility of the proposed control strategy is verified through comparative simulations and experiments.
Graphical Abstract
Keywords
Data Availability Statement
Funding
Conflicts of Interest
Ethical Approval and Consent to Participate
References
- Zhu, G., Dessaint, L. A., Akhrif, O., & Kaddouri, A. (2000). Speed tracking control of a permanent-magnet synchronous motor with state and load torque observer. IEEE transactions on industrial electronics, 47(2), 346-355.
[CrossRef] [Google Scholar] - Chen, Q., Ren, X., Na, J., & Zheng, D. (2017). Adaptive robust finite-time neural control of uncertain PMSM servo system with nonlinear dead zone. Neural Computing and Applications, 28(12), 3725-3736.
[CrossRef] [Google Scholar] - Xu, B., Zhang, L., & Ji, W. (2021). Improved non-singular fast terminal sliding mode control with disturbance observer for PMSM drives. IEEE Transactions on Transportation Electrification, 7(4), 2753-2762.
[CrossRef] [Google Scholar] - Na, J., Jing, B., Huang, Y., Gao, G., & Zhang, C. (2019). Unknown system dynamics estimator for motion control of nonlinear robotic systems. IEEE Transactions on Industrial Electronics, 67(5), 3850-3859.
[CrossRef] [Google Scholar] - Nguyen, V. T., Bui, T. T., & Pham, H. Y. (2023). A finite-time adaptive fault tolerant control method for a robotic manipulator in task-space with dead zone, and actuator faults. International Journal of Control, Automation and Systems, 21(11), 3767-3776.
[CrossRef] [Google Scholar] - Zhang, Z., Yang, C., & Ge, S. S. (2022). Decentralized adaptive control of large-scale nonlinear systems with time-delay interconnections and asymmetric dead-zone input. IEEE Transactions on Systems, Man, and Cybernetics: Systems, 53(4), 2259-2270.
[CrossRef] [Google Scholar] - Ibrir, S., & Su, C. Y. (2010). Simultaneous state and dead-zone parameter estimation for a class of bounded-state nonlinear systems. IEEE transactions on control systems technology, 19(4), 911-919.
[CrossRef] [Google Scholar] - Na, J., He, H., Huang, Y., & Dong, R. (2021). Adaptive estimation of asymmetric dead-zone parameters for sandwich systems. IEEE Transactions on Control Systems Technology, 30(3), 1336-1344.
[CrossRef] [Google Scholar] - Na, J., Xing, Y., & Costa-Castelló, R. (2018). Adaptive estimation of time-varying parameters with application to roto-magnet plant. IEEE Transactions on Systems, Man, and Cybernetics: Systems, 51(2), 731-741.
[CrossRef] [Google Scholar] - He, H., Na, J., Wu, J., Huang, Y., & Xing, Y. (2023). Fixed-time adaptive parameter estimation for Hammerstein systems subject to dead-zone. IEEE Transactions on Industrial Electronics, 71(4), 3862-3872.
[CrossRef] [Google Scholar] - Chiu, S. (2012). Derivative and integral terminal sliding mode control for a class of MIMO nonlinear systems. Automatica, 48(2), 316–326.
[CrossRef] [Google Scholar] - Yang, C., Jiang, Y., He, W., Na, J., Li, Z., & Xu, B. (2018). Adaptive parameter estimation and control design for robot manipulators with finite-time convergence. IEEE Transactions on Industrial Electronics, 65(10), 8112-8123.
[CrossRef] [Google Scholar] - Zuo, Z. (2015). Non‐singular fixed‐time terminal sliding mode control of non‐linear systems. IET control theory & applications, 9(4), 545-552.
[CrossRef] [Google Scholar] - Ni, J., Liu, L., Liu, C., Hu, X., & Li, S. (2016). Fast fixed-time nonsingular terminal sliding mode control and its application to chaos suppression in power system. IEEE Transactions on Circuits and Systems II: Express Briefs, 64(2), 151-155.
[CrossRef] [Google Scholar] - Wang, H., Li, S., Lan, Q., Zhao, Z., & Zhou, X. (2017). Continuous terminal sliding mode control with extended state observer for PMSM speed regulation system. Transactions of the Institute of Measurement and Control, 39(8), 1195-1204.
[CrossRef] [Google Scholar] - Li, S., Zhou, M., & Yu, X. (2012). Design and implementation of terminal sliding mode control method for PMSM speed regulation system. IEEE Transactions on Industrial Informatics, 9(4), 1879-1891.
[CrossRef] [Google Scholar] - Wang, S. (2004). General constructive representations for continuous piecewise-linear functions. IEEE Transactions on Circuits and Systems I: Regular Papers, 51(9), 1889-1896.
[CrossRef] [Google Scholar] - Cui, L., Jin, N., Chang, S., Zuo, Z., & Zhao, Z. (2022). Fixed-time ESO based fixed-time integral terminal sliding mode controller design for a missile. ISA transactions, 125, 237-251.
[CrossRef] [Google Scholar] - Liu, C., & Liu, Y. (2022). Finite-time stabilization with arbitrarily prescribed settling-time for uncertain nonlinear systems. Systems & Control Letters, 159, 105088.
[CrossRef] [Google Scholar] - Wang, W., Xie, B., Zuo, Z., & Fan, H. (2018). Adaptive backstepping control of uncertain gear transmission servosystems with asymmetric dead-zone nonlinearity. IEEE Transactions on Industrial Electronics, 66(5), 3752-3762.
[CrossRef] [Google Scholar] - Aranovskiy, S., Bobtsov, A., Ortega, R., & Pyrkin, A. (2016). Performance enhancement of parameter estimators via dynamic regressor extension and mixing. IEEE Transactions on Automatic Control, 62(7), 3546-3550.
[CrossRef] [Google Scholar] - Wang, S., Na, J., & Xing, Y. (2020). Adaptive optimal parameter estimation and control of servo mechanisms: Theory and experiments. IEEE Transactions on Industrial Electronics, 68(1), 598-608.
[CrossRef] [Google Scholar] - Na, J., Mahyuddin, M. N., Herrmann, G., Ren, X., & Barber, P. (2015). Robust adaptive finite‐time parameter estimation and control for robotic systems. International Journal of Robust and Nonlinear Control, 25(16), 3045-3071.
[CrossRef] [Google Scholar]
Cited By (4)
-
Yuan Liu, Lianpeng Zhang, Ruichen Wang, Litong Lyu, Jie Feng, Guangtao Ma. Adaptive integral sliding mode control for attitude tracking of 6-DOF electro-hydraulic shaking tables.
Journal of Measurements in Engineering, 2026 , 14 (2).
[CrossRef] -
Zi-Yun Wang, Li-Ping Liao, Qian-Yi Shen, Yan Wang, Zhen-Hua Wang. Design of a Novel Particle-Based Zonotopic Hybrid Filter and its Application.
IEEE Transactions on Industrial Informatics, 2026 , 22 (6).
[CrossRef] -
Felix Buck, Christoph Imdahl Habel, Nikolas Dilger, Sabrina Zellmer, Christoph Herrmann. Iterative approach for scaling machine parameters to desired scale.
Results in Engineering, 2026 , 32 .
[CrossRef] -
Yuxin Jia, Nan Guo, |Tiewei Shang, Wenlu Li, Yueyang Sun, Junfei Qiao. A Bayesian‐Optimized GRU Network With WMD‐EFAST Self‐Organizing Mechanism for Multimodal Atmospheric Pollutant Prediction.
International Journal of Adaptive Control and Signal Processing, 2026 .
[CrossRef]
Cite This Article
TY  - JOUR
AU  - Wang, Shubo
AU  - Wang, Xue
PY  - 2025
DA  - 2025/08/28
TI  - Fixed-Time Adaptive Optimal Parameter Estimation Subject to Dead-Zone and Control of Servo Systems
JO  - ICCK Transactions on Sensing, Communication, and Control
T2  - ICCK Transactions on Sensing, Communication, and Control
JF  - ICCK Transactions on Sensing, Communication, and Control
VL  - 2
IS  - 3
SP  - 200
EP  - 214
DO  - 10.62762/TSCC.2025.143677
UR  - https://www.icck.org/article/abs/TSCC.2025.143677
KW  - servo system
KW  - adaptive optimal parameter estimation
KW  - fixed-time convergence
KW  - dead-zone
KW  - sliding mode control
AB  - A fixed-time adaptive optimal parameter estimation (FxT-AOPE) scheme is proposed to address the difficulties in estimating dead zone parameters and slow convergence speed of tracking errors in permanent magnet synchronous motor systems. First, the continuous piecewise linear neural network is used to model the nonlinear dead zone dynamics. Second, an auxiliary filter is constructed to extract estimation errors, and this filter is used to drive an adaptive law with time-varying gain, minimizing the cost function of estimation errors and achieving adaptive optimal parameter estimation (AOPE). Then, the AOPE method is introduced into the fixed-time non-singular terminal sliding mode control (FxT-NTSMC) of the permanent magnet synchronous motor system, and the FxT-AOPE strategy is proposed to ensure the fixed-time convergence of estimation error and tracking error. The stability of the closed-loop system is analyzed using Lyapunov stability theory. Finally, the feasibility of the proposed control strategy is verified through comparative simulations and experiments.
SN  - 3068-9287
PB  - Institute of Central Computation and Knowledge
LA  - English
ER  -
@article{Wang2025FixedTime,
  author = {Shubo Wang and Xue Wang},
  title = {Fixed-Time Adaptive Optimal Parameter Estimation Subject to Dead-Zone and Control of Servo Systems},
  journal = {ICCK Transactions on Sensing, Communication, and Control},
  year = {2025},
  volume = {2},
  number = {3},
  pages = {200-214},
  doi = {10.62762/TSCC.2025.143677},
  url = {https://www.icck.org/article/abs/TSCC.2025.143677},
  abstract = {A fixed-time adaptive optimal parameter estimation (FxT-AOPE) scheme is proposed to address the difficulties in estimating dead zone parameters and slow convergence speed of tracking errors in permanent magnet synchronous motor systems. First, the continuous piecewise linear neural network is used to model the nonlinear dead zone dynamics. Second, an auxiliary filter is constructed to extract estimation errors, and this filter is used to drive an adaptive law with time-varying gain, minimizing the cost function of estimation errors and achieving adaptive optimal parameter estimation (AOPE). Then, the AOPE method is introduced into the fixed-time non-singular terminal sliding mode control (FxT-NTSMC) of the permanent magnet synchronous motor system, and the FxT-AOPE strategy is proposed to ensure the fixed-time convergence of estimation error and tracking error. The stability of the closed-loop system is analyzed using Lyapunov stability theory. Finally, the feasibility of the proposed control strategy is verified through comparative simulations and experiments.},
  keywords = {servo system, adaptive optimal parameter estimation, fixed-time convergence, dead-zone, sliding mode control},
  issn = {3068-9287},
  publisher = {Institute of Central Computation and Knowledge}
}
Publisher's Note
ICCK stays neutral with regard to jurisdictional claims in published maps and institutional affiliations.
Rights and Permissions
Portico