Research Article
Free to Read
Primary Thought on the Incorporation of Intelligent Control and U-control (I-U-control)

1
School of Engineering, University of the West of England, Bristol BS16 1QY, United Kingdom
2
College of Information Science and Technology, Qingdao University of Science and Technology, Qingdao 266061, China
* Corresponding Author:
Haihong Wang,
[email protected]
Volume 2, Issue 3
2025
Received: 05 April 2025
Revised: 03 May 2025
Accepted: 06 May 2025
Published: 20 July 2025
You have access to this article
·
Limited-Time Free Access
Article Information
Abstract
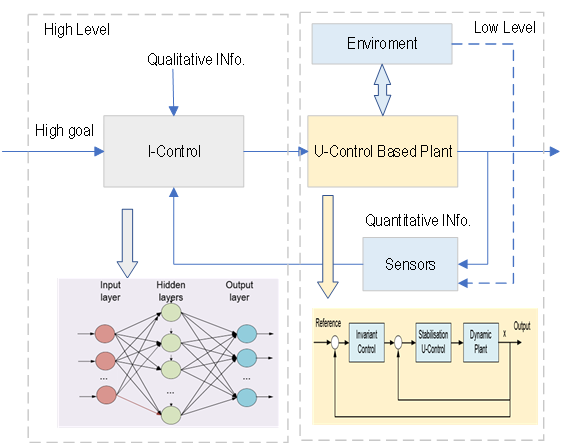
This study explains the main idea and structure of an integrated What-How intelligent control and universal control (I-U-control) system. The proposed framework consists of two control layers. The bottom layer uses the U-control framework to manage 'How' to control within a universal framework. The top layer uses intelligent control (I-control) to coordinate and guide 'What' to achieve both global and local control goals. This study also reviews the configurations, functions, and integration of these two control layers in analysis, design, and applications.
Graphical Abstract
Keywords
universal(U)-control
data-driven operation
control Lyapunov stability
lyapunov derivative inequality
intelligent (I)-control
goal-oriented control systems (GOCS)
What-How intelligent control systems (WH-ICS)
Data Availability Statement
Data will be made available on request.
Funding
This work was supported without any funding.
Conflicts of Interest
Quanmin Zhu served as an Associate Editor of the ICCK Transactions on Sensing, Communication, and Control at the time of manuscript submission. To ensure the integrity of the peer-review process, Quanmin Zhu was not involved in the editorial handling, peer review, or decision-making process for this manuscript, which was handled independently by another editor. The remaining author declares no conflicts of interest.
Ethical Approval and Consent to Participate
Not applicable.
References
- Zhu, Q., Zhang, W., Li, S., Chen, Q., Na, J., & Ding, H. (2025). U-control–a universal platform for control system design with inversion/cancellation of nonlinearity, dynamic and coupling through model-based to model-free procedures. International Journal of Systems Science, 56(3), 484-501.
[CrossRef] [Google Scholar] - Qin, S. J., & Badgwell, T. A. (2003). A survey of industrial model predictive control technology. Control engineering practice, 11(7), 733-764.
[CrossRef] [Google Scholar] - Zhu, Q., Li, R., & Zhang, J. (2023). Model-free robust decoupling control of nonlinear nonaffine dynamic systems. International Journal of Systems Science, 54(13), 2590-2607.
[CrossRef] [Google Scholar] - Antsaklis, P. (1993). Defining intelligent control. Report of the Task Force on Intelligent Control IEEE Control Systems Society. https://ieeecss.org/sites/ieeecss/files/2021-03/isis-94-001-DefiningIntelligentControl_2.pdf
[Google Scholar] - Grosan, C., Abraham, A., Jain, L. C., & Kacprzyk, J. (2011). Intelligent systems (Vol. 17, pp. 261-268). Berlin: Springer.
[CrossRef] [Google Scholar] - Shi, P., & Yan, B. (2020). A survey on intelligent control for multiagent systems. IEEE Transactions on Systems, Man, and Cybernetics: Systems, 51(1), 161-175.
[CrossRef] [Google Scholar] - Zaitceva, I., & Andrievsky, B. (2022). Methods of intelligent control in mechatronics and robotic engineering: A survey. Electronics, 11(15), 2443.
[CrossRef] [Google Scholar] - Blum, C., & Roli, A. (2003). Metaheuristics in combinatorial optimization: Overview and conceptual comparison. ACM computing surveys (CSUR), 35(3), 268-308.
[CrossRef] [Google Scholar] - Yang, X. S. (Ed.). (2015). Recent advances in swarm intelligence and evolutionary computation (p. 303). Switzerland: Springer International Publishing.
[CrossRef] [Google Scholar] - Dorigo, M., & Stützle, T. (2018). Ant colony optimization: overview and recent advances. Handbook of metaheuristics, 311-351.
[CrossRef] [Google Scholar] - Malhotra, R., Singh, N., & Singh, Y. (2011). Genetic algorithms: Concepts, design for optimization of process controllers. Computer and information science, 4(2), 39.
[CrossRef] [Google Scholar] - Das, S., & Suganthan, P. N. (2010). Differential evolution: A survey of the state-of-the-art. IEEE transactions on evolutionary computation, 15(1), 4-31.
[CrossRef] [Google Scholar] - Naeem, S., Ali, A., Anam, S., & Ahmed, M. M. (2023). An unsupervised machine learning algorithms: Comprehensive review. International Journal of Computing and Digital Systems. http://dx.doi.org/10.12785/ijcds/130172
[Google Scholar] - Choi, W. H., & Kim, J. (2024). Unsupervised learning approach for anomaly detection in industrial control systems. Applied System Innovation, 7(2), 18.
[CrossRef] [Google Scholar] - Garaffa, L. C., Basso, M., Konzen, A. A., & de Freitas, E. P. (2021). Reinforcement learning for mobile robotics exploration: A survey. IEEE Transactions on Neural Networks and Learning Systems, 34(8), 3796-3810.
[CrossRef] [Google Scholar] - Zhao, W., Queralta, J. P., & Westerlund, T. (2020, December). Sim-to-real transfer in deep reinforcement learning for robotics: a survey. In 2020 IEEE symposium series on computational intelligence (SSCI) (pp. 737-744). IEEE.
[CrossRef] [Google Scholar] - Gu, S., Holly, E., Lillicrap, T., & Levine, S. (2017, May). Deep reinforcement learning for robotic manipulation with asynchronous off-policy updates. In 2017 IEEE international conference on robotics and automation (ICRA) (pp. 3389-3396). IEEE.
[CrossRef] [Google Scholar] - Kuhnle, A., Kaiser, J. P., Theiß, F., Stricker, N., & Lanza, G. (2021). Designing an adaptive production control system using reinforcement learning. Journal of Intelligent Manufacturing, 32, 855-876.
[CrossRef] [Google Scholar] - Xin, Q., Wu, G., Fang, W., Cao, J., & Ping, Y. (2021, October). Opportunities for reinforcement learning in industrial automation. In 2021 7th International Conference on Big Data and Information Analytics (BigDIA) (pp. 496-504). IEEE.
[CrossRef] [Google Scholar] - Wen, T., Fang, Y., & Lu, B. (2022). Neural network-based adaptive sliding mode control for underactuated dual overhead cranes suffering from matched and unmatched disturbances. Autonomous Intelligent Systems, 2(1), 1.
[CrossRef] [Google Scholar] - Refoufi, S., & Benmahammed, K. (2018). Control of a manipulator robot by neuro-fuzzy subsets form approach control optimized by the genetic algorithms. ISA transactions, 77, 133-145.
[CrossRef] [Google Scholar] - Chojecki, A., Ambroziak, A., & Borkowski, P. (2023). Fuzzy controllers instead of classical PIDs in HVAC equipment: Dusting off a well-known technology and Today's implementation for better energy efficiency and user comfort. Energies, 16(7), 2967.
[CrossRef] [Google Scholar] - Mamdani, E. H., & Assilian, S. (1999). An experiment in linguistic synthesis with a fuzzy logic controller. International journal of human-computer studies, 51(2), 135-147.
[CrossRef] [Google Scholar] - Precup, R. E., & Hellendoorn, H. (2011). A survey on industrial applications of fuzzy control. Computers in industry, 62(3), 213-226.
[CrossRef] [Google Scholar] - Iqbal, R., Maniak, T., Doctor, F., & Karyotis, C. (2019). Fault detection and isolation in industrial processes using deep learning approaches. IEEE Transactions on Industrial Informatics, 15(5), 3077-3084.
[CrossRef] [Google Scholar] - Yang, W., Wei, Y., Wei, H., Chen, Y., Huang, G., Li, X., ... & Kang, B. (2023). Survey on explainable AI: From approaches, limitations and applications aspects. Human-Centric Intelligent Systems, 3(3), 161-188.
[CrossRef] [Google Scholar] - Cao, Y., Yu, W., Ren, W., & Chen, G. (2012). An overview of recent progress in the study of distributed multi-agent coordination. IEEE Transactions on Industrial informatics, 9(1), 427-438.
[CrossRef] [Google Scholar] - Lillicrap, T. P., Hunt, J. J., Pritzel, A., Heess, N., Erez, T., Tassa, Y., ... & Wierstra, D. (2015). Continuous control with deep reinforcement learning. arXiv preprint arXiv:1509.02971.
[CrossRef] [Google Scholar] - Zhu, Q. (2023). Model-free sliding mode enhanced proportional, integral, and derivative (SMPID) control. Axioms, 12(8), 721.
[CrossRef] [Google Scholar] - Scattolini, R. (2009). Architectures for distributed and hierarchical model predictive control–a review. Journal of process control, 19(5), 723-731.
[CrossRef] [Google Scholar] - Vallon, C., Pustilnik, M., Pinto, A., & Borrelli, F. (2024). Learning hierarchical control systems for autonomous systems with energy constraints. arXiv preprint arXiv:2403.14536.
[CrossRef] [Google Scholar] - Farina, M., & Scattolini, R. (2019). Distributed MPC for large-scale systems. Handbook of Model Predictive Control, 239-258.
[CrossRef] [Google Scholar] - Yang, X., & Zhou, Y. (2024). Energy Management of Plug-In Hybrid Electric Vehicles for Autonomous Driving in a Following Environment Based on Fuzzy Adaptive PID Control. IEEE Access.
[CrossRef] [Google Scholar] - Chen, W. H. (2024). Goal-oriented control systems (gocs): From how to what. IEEE/CAA Journal of Automatica Sinica, 11(4), 816-819.
[CrossRef] [Google Scholar] - Liu, D., Xue, S., Zhao, B., Luo, B., & Wei, Q. (2020). Adaptive dynamic programming for control: A survey and recent advances. IEEE Transactions on Systems, Man, and Cybernetics: Systems, 51(1), 142-160.
[CrossRef] [Google Scholar] - Zhao, Y., Du, X., Xia, G., & Wu, L. (2015). A novel algorithm for wavelet neural networks with application to enhanced PID controller design. Neurocomputing, 158, 257-267.
[CrossRef] [Google Scholar] - Giernacki, W. (2022). Minimum energy control of quadrotor UAV: Synthesis and performance analysis of control system with neurobiologically inspired intelligent controller (BELBIC). Energies, 15(20), 7566.
[CrossRef] [Google Scholar] - Hou, Z., & Xiong, S. (2019). On model-free adaptive control and its stability analysis. IEEE Transactions on Automatic Control, 64(11), 4555-4569.
[CrossRef] [Google Scholar] - Wang, C. S., & Wu, M. (2011). Hierarchical intelligent control system and its application to the sintering process. IEEE Transactions on Industrial Informatics, 9(1), 190-197.
[CrossRef] [Google Scholar] - Abdullah, F. M., Al-Ahmari, A. M., & Anwar, S. (2023). A hybrid fuzzy multi-criteria decision-making model for evaluating the influence of Industry 4.0 technologies on manufacturing strategies. Machines, 11(2), 310.
[CrossRef] [Google Scholar] - Hussain, N. A. A., Ali, S. S. A., Ovinis, M., Arshad, M. R., & Al-Saggaf, U. M. (2019). Underactuated coupled nonlinear adaptive control synthesis using U-model for multivariable unmanned marine robotics. IEEE Access, 8, 1851-1865.
[CrossRef] [Google Scholar] - Wang, R., Gao, L., Bai, C., & Sun, H. (2020). U‐Model‐Based Sliding Mode Controller Design for Quadrotor UAV Control Systems. Mathematical Problems in Engineering, 2020(1), 4343214.
[CrossRef] [Google Scholar]
Cited By (4)
-
Xiaohui Cong, Yunlong Zhang, Haixia Zhao. Structural capacity and impact behavior of circular bridge piers strengthened by concrete jacketing.
Journal of Vibroengineering, 2026 , 28 (5).
[CrossRef] -
Yuan Liu, Lianpeng Zhang, Ruichen Wang, Litong Lyu, Jie Feng, Guangtao Ma. Adaptive integral sliding mode control for attitude tracking of 6-DOF electro-hydraulic shaking tables.
Journal of Measurements in Engineering, 2026 , 14 (2).
[CrossRef] -
Suresha Devaraju, Dhivya Muthusamy, Santosh Kenchappa Chandrappa, Chandru Jathar, Srinu Banothu, Athiraja Atheeswaran. Smart hydroponic farming system using IoT-integrated deep learning for real-time nutrient monitoring and climate control.
Ecohydrology & Hydrobiology, 2026 , 26 (2).
[CrossRef] -
Guixin Li, Bingjin Zhou, Minjian Ni, Huiying Chen, Yiwei Liu, Yinghua Zhang, Man Zhang, Minjuan Wang. MMIU-Net: an encoder–decoder architecture based on multimodal feature fusion for wheat yield prediction under drought stress.
International Journal of Remote Sensing, 2026 , 47 (13).
[CrossRef]
* Citation data provided by Crossref Cited-by.
Cite This Article
APA Style
Zhu, Q., & Wang, H. (2025). Primary Thought on the Incorporation of Intelligent Control and U-control (I-U-control). ICCK Transactions on Sensing, Communication, and Control, 2(3), 132-146. https://doi.org/10.62762/TSCC.2025.880778
Export Citation
RIS Format
Compatible with EndNote, Zotero, Mendeley, and other reference managers
TY  - JOUR
AU  - Zhu, Quanmin
AU  - Wang, Haihong
PY  - 2025
DA  - 2025/07/20
TI  - Primary Thought on the Incorporation of Intelligent Control and U-control (I-U-control)
JO  - ICCK Transactions on Sensing, Communication, and Control
T2  - ICCK Transactions on Sensing, Communication, and Control
JF  - ICCK Transactions on Sensing, Communication, and Control
VL  - 2
IS  - 3
SP  - 132
EP  - 146
DO  - 10.62762/TSCC.2025.880778
UR  - https://www.icck.org/article/abs/TSCC.2025.880778
KW  - universal(U)-control
KW  - data-driven operation
KW  - control Lyapunov stability
KW  - lyapunov derivative inequality
KW  - intelligent (I)-control
KW  - goal-oriented control systems (GOCS)
KW  - What-How intelligent control systems (WH-ICS)
AB  - This study explains the main idea and structure of an integrated What-How intelligent control and universal control (I-U-control) system. The proposed framework consists of two control layers. The bottom layer uses the U-control framework to manage 'How' to control within a universal framework. The top layer uses intelligent control (I-control) to coordinate and guide 'What' to achieve both global and local control goals. This study also reviews the configurations, functions, and integration of these two control layers in analysis, design, and applications.
SN  - 3068-9287
PB  - Institute of Central Computation and Knowledge
LA  - English
ER  -
BibTeX Format
Compatible with LaTeX, BibTeX, and other reference managers
@article{Zhu2025Primary,
  author = {Quanmin Zhu and Haihong Wang},
  title = {Primary Thought on the Incorporation of Intelligent Control and U-control (I-U-control)},
  journal = {ICCK Transactions on Sensing, Communication, and Control},
  year = {2025},
  volume = {2},
  number = {3},
  pages = {132-146},
  doi = {10.62762/TSCC.2025.880778},
  url = {https://www.icck.org/article/abs/TSCC.2025.880778},
  abstract = {This study explains the main idea and structure of an integrated What-How intelligent control and universal control (I-U-control) system. The proposed framework consists of two control layers. The bottom layer uses the U-control framework to manage 'How' to control within a universal framework. The top layer uses intelligent control (I-control) to coordinate and guide 'What' to achieve both global and local control goals. This study also reviews the configurations, functions, and integration of these two control layers in analysis, design, and applications.},
  keywords = {universal(U)-control, data-driven operation, control Lyapunov stability, lyapunov derivative inequality, intelligent (I)-control, goal-oriented control systems (GOCS), What-How intelligent control systems (WH-ICS)},
  issn = {3068-9287},
  publisher = {Institute of Central Computation and Knowledge}
}
Publisher's Note
ICCK stays neutral with regard to jurisdictional claims in published maps and institutional affiliations.
Rights and Permissions
Institute of Central Computation and Knowledge (ICCK) or its licensor holds exclusive rights to this article under a publishing agreement with the author(s) or other rightsholder(s); author self-archiving of the accepted manuscript version of this article is solely governed by the terms of such publishing agreement and applicable law.
ICCK Transactions on Sensing, Communication, and Control
ISSN: 3068-9287 (Online)
| ISSN: 3068-9279 (Print)
Preserved at
Portico
Portico

Scan to read this article