Signal Strength-Based Alien Drone Detection and Containment in Indoor UAV Swarm Simulations

Article Information
Abstract
A Novel simulation framework using autonomous drones is used to locate and reduce unauthorized drones in interior environments. The recommended method uses Received Signal Strength Indicator (RSSI) to identify an alien agent drone, which has different signal characteristics than the approved swarm of UAVs. Real-time threat detection is possible with this technology. After detecting the drone, the swarm organizes itself to encircle and contain it for 20 seconds, rendering it immobilized, before the swarm returns to its original formation. This unique solution uses RSSI to quickly identify and mitigate enclosed area concerns. It provides a reliable and effective indoor drone security solution. The simulation results show that the approach works in critical environments such as warehouses, laboratories, and other secure indoor facilities. This study advances unmanned aerial system (UAS) autonomous swarm intelligence and security procedures.
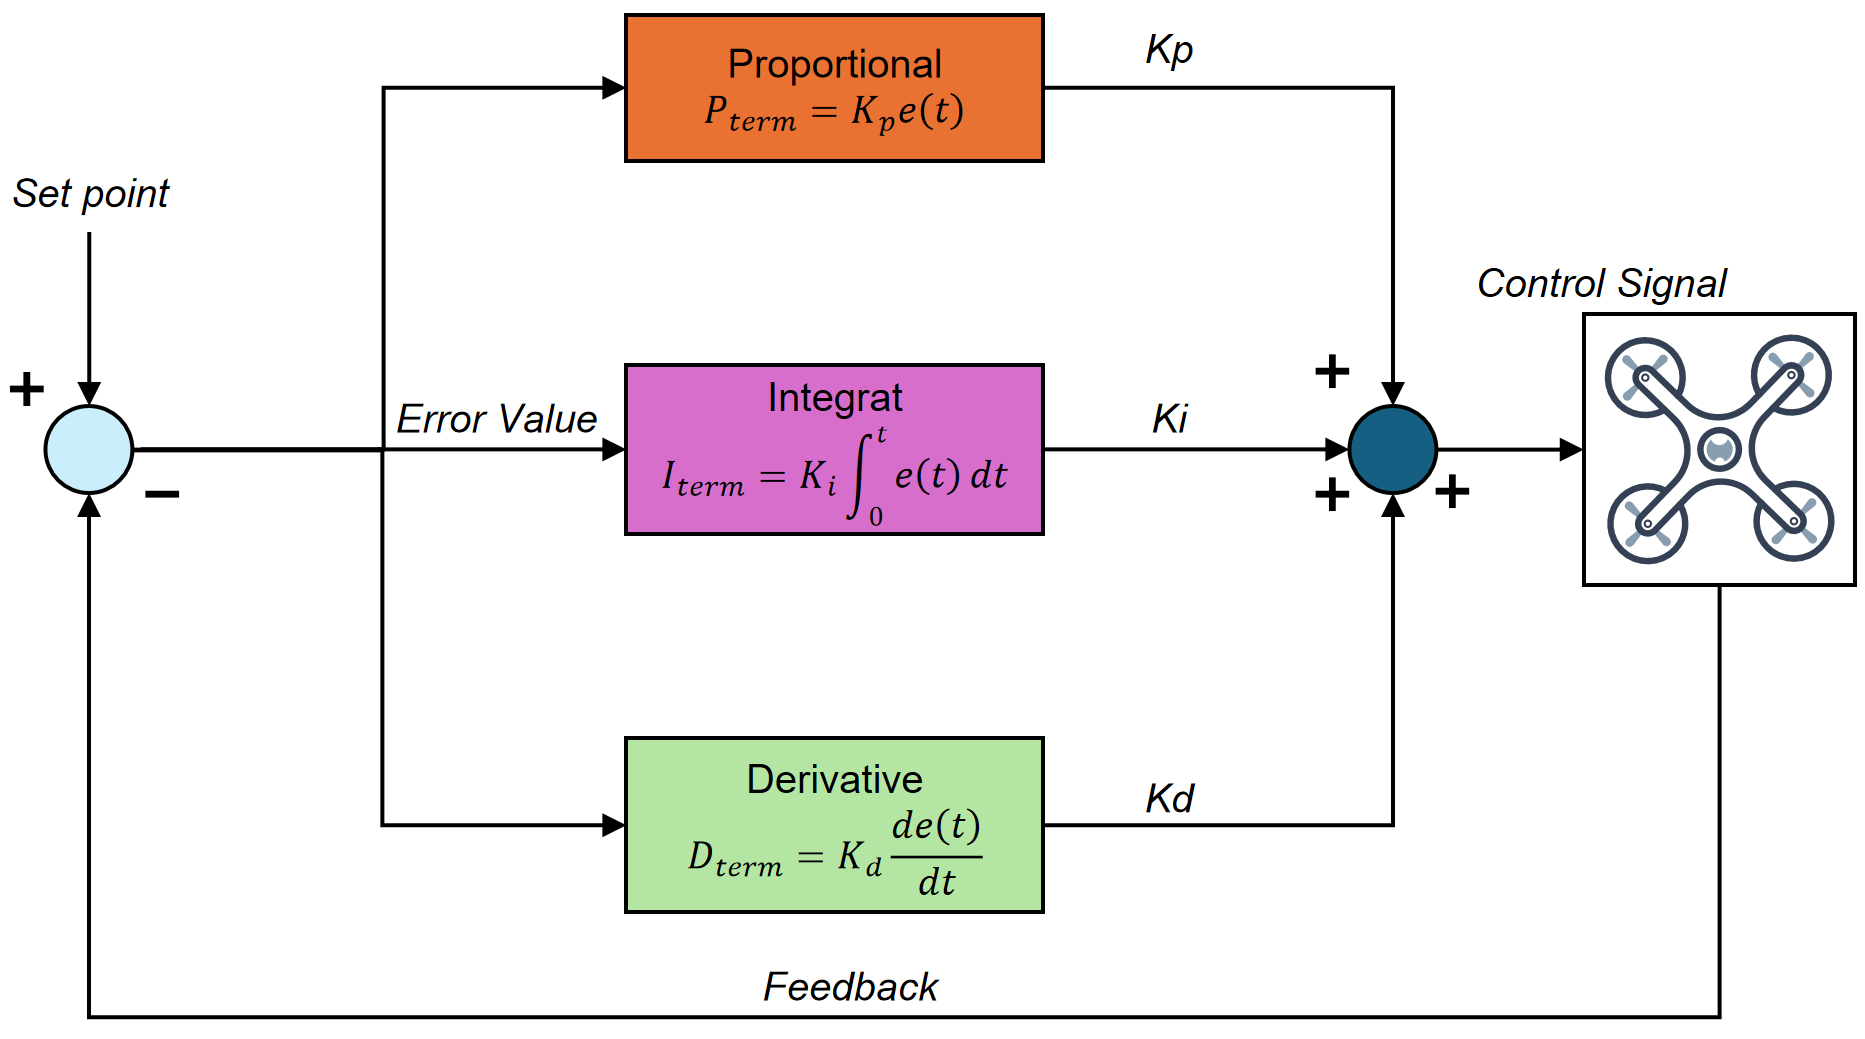
Graphical Abstract
Keywords
Data Availability Statement
Funding
Conflicts of Interest
Ethical Approval and Consent to Participate
References
- Adnan, W. H., & Khamis, M. F. (2022). Drone use in military and civilian application: Risk to national security. Journal of Media and Information Warfare (JMIW), 15(1), 60-70. https://ir.uitm.edu.my/id/eprint/58297/
[Google Scholar] - Day, D. (2017). Drones for transmission infrastructure inspection and mapping improve efficiency. Natural Gas & Electricity, 33(12), 7-11.
[CrossRef] [Google Scholar] - Tomic, T., Schmid, K., Lutz, P., Domel, A., Kassecker, M., Mair, E., ... & Burschka, D. (2012). Toward a fully autonomous UAV: Research platform for indoor and outdoor urban search and rescue. IEEE robotics & automation magazine, 19(3), 46-56.
[CrossRef] [Google Scholar] - Famili, A., Stavrou, A., Wang, H., & Park, J. M. (2022). Pilot: High-precision indoor localization for autonomous drones. IEEE Transactions on Vehicular Technology, 72(5), 6445-6459.
[CrossRef] [Google Scholar] - Shakhatreh, H., Sawalmeh, A. H., Al-Fuqaha, A., Dou, Z., Almaita, E., Khalil, I., ... & Guizani, M. (2019). Unmanned aerial vehicles (UAVs): A survey on civil applications and key research challenges. IEEE Access, 7, 48572-48634.
[CrossRef] [Google Scholar] - Awasthi, S., Fernandez-Cortizas, M., Reining, C., Arias-Perez, P., Luna, M. A., Perez-Saura, D., ... & Campoy, P. (2023). Micro UAV Swarm for industrial applications in indoor environment: A systematic literature review. Logistics Research, 16(1), 1-43.
[CrossRef] [Google Scholar] - Zhou, Y., Rao, B., & Wang, W. (2020). UAV swarm intelligence: Recent advances and future trends. Ieee Access, 8, 183856-183878.
[CrossRef] [Google Scholar] - Campion, M., Ranganathan, P., & Faruque, S. (2018). UAV swarm communication and control architectures: a review. Journal of Unmanned Vehicle Systems, 7(2), 93-106.
[CrossRef] [Google Scholar] - Nemer, I., Sheltami, T., Ahmad, I., Yasar, A. U. H., & Abdeen, M. A. (2021). RF-based UAV detection and identification using hierarchical learning approach. Sensors, 21(6), 1947.
[CrossRef] [Google Scholar] - Coppola, M., McGuire, K. N., De Wagter, C., & De Croon, G. C. (2020). A survey on swarming with micro air vehicles: Fundamental challenges and constraints. Frontiers in Robotics and AI, 7, 18.
[CrossRef] [Google Scholar] - Xiaoning, Z. (2020, November). Analysis of military application of UAV swarm technology. In 2020 3rd International Conference on Unmanned Systems (ICUS) (pp. 1200-1204). IEEE.
[CrossRef] [Google Scholar] - Vanhie-Van Gerwen, J., Geebelen, K., Wan, J., Joseph, W., Hoebeke, J., & De Poorter, E. (2021). Indoor drone positioning: Accuracy and cost trade-off for sensor fusion. IEEE Transactions on Vehicular Technology, 71(1), 961-974.
[CrossRef] [Google Scholar] - Pérez, M. C., Gualda, D., Vicente, J., Villadangos, J. M., & Ureña, J. (2019, September). Review of UAV positioning in indoor environments and new proposal based on US measurements. In CEUR Workshop Proc (Vol. 2498, pp. 267-274).
[Google Scholar] - Xu, S., Zhang, L., Wang, X., Chen, J., Wei, F., & Wu, Y. (2023). Indoor cooperative localization for a swarm of micro UAVs based on visible light communication. IEEE Systems Journal, 17(4), 6504-6515.
[CrossRef] [Google Scholar] - Youn, W., Ko, H., Choi, H., Choi, I., Baek, J. H., & Myung, H. (2021). Collision-free autonomous navigation of a small UAV using low-cost sensors in GPS-denied environments. International Journal of Control, Automation and Systems, 19(2), 953-968.
[CrossRef] [Google Scholar] - Famili, A., & Park, J. M. J. (2020, May). ROLATIN: Robust localization and tracking for indoor navigation of drones. In 2020 IEEE Wireless Communications and Networking Conference (WCNC) (pp. 1-6). IEEE.
[CrossRef] [Google Scholar] - Safaei, A., & Sharf, I. (2021, June). Velocity estimation for UAVs using ultra wide-band system. In 2021 International Conference on Unmanned Aircraft Systems (ICUAS) (pp. 202-209). IEEE.
[CrossRef] [Google Scholar] - Sun, Y., Wang, W., Mottola, L., Zhang, J., Wang, R., & He, Y. (2023). Indoor drone localization and tracking based on acoustic inertial measurement. IEEE Transactions on Mobile Computing, 23(6), 7537-7551.
[CrossRef] [Google Scholar] - Brust, M. R., Danoy, G., Stolfi, D. H., & Bouvry, P. (2021). Swarm-based counter UAV defense system. Discover Internet of Things, 1(1), 2.
[CrossRef] [Google Scholar] - Horyna, J., Baca, T., Walter, V., Albani, D., Hert, D., Ferrante, E., & Saska, M. (2023). Decentralized swarms of unmanned aerial vehicles for search and rescue operations without explicit communication. Autonomous Robots, 47(1), 77-93.
[CrossRef] [Google Scholar] - DURDU, A., & KAYABAŞI, A. (2024). Consensus-based virtual leader tracking algorithm for flight formation control of swarm UAVs. Turkish Journal of Electrical Engineering and Computer Sciences, 32(2), 251-267.
[CrossRef] [Google Scholar]
Cited By (7)
-
Tanishq Srivastava, S. D. Bhuvana, Prathvi Shenoy, Rahul Ratnakumar. A Reconfigurable Fuzzy-Logic Audio-Visual Fusion Implementation for Area Threat Identification.
IEEE Access, 2026 , 14 .
[CrossRef] -
Mateus de Sousa, Rafael M. Duarte, Moises Nuñez, Juan M. M. Villanueva. Development of a Data Collection and Data Transmission System Using Drones and IoT Sensors.
Journal of Advances in Information Technology, 2025 , 16 (11).
[CrossRef] -
Qingcheng Chen. .
2025 7th International Conference on Intelligent Control, Measurement and Signal Processing (ICMSP), 2025 .
[CrossRef] -
Meishuang Yan, Lu Chen, Wei Hu, Zhihong Sun, Xueguang Zhou. Secure and Intelligent Single-Channel Blind Source Separation via Adaptive Variational Mode Decomposition with Optimized Parameters.
Sensors, 2025 , 25 (4).
[CrossRef] -
Ghulam E Mustafa Abro, Ayman M Abdallah. Graph Attention Networks For Anomalous Drone Detection: RSSI-Based Approach with Real-world Validation.
Expert Systems with Applications, 2025 , 273 .
[CrossRef] -
Ghulam E Mustafa Abro. Trajectory optimisation for swarm UAVs in constrained environments with RSSI-based FOPID control.
Discover Electronics, 2025 , 2 (1).
[CrossRef] -
Xinghong Yang, Lizhen Shao. Green and efficient path planning framework based on multi-granularity view fusion for amphibious unmanned aerial vehicles.
Engineering Applications of Artificial Intelligence, 2025 , 151 .
[CrossRef]
Cite This Article
TY  - JOUR
AU  - Abro, Ghulam E Mustafa
AU  - Ali, Zain Anwar
AU  - Abdallah, Ayman M
PY  - 2024
DA  - 2024/09/23
TI  - Signal Strength-Based Alien Drone Detection and Containment in Indoor UAV Swarm Simulations
JO  - ICCK Transactions on Intelligent Systematics
T2  - ICCK Transactions on Intelligent Systematics
JF  - ICCK Transactions on Intelligent Systematics
VL  - 1
IS  - 2
SP  - 69
EP  - 78
DO  - 10.62762/TIS.2024.807714
UR  - https://www.icck.org/article/abs/TIS.2024.807714
KW  - autonomous drone swarms
KW  - RSSI
KW  - indoor security
KW  - unmanned aerial vehicle (UAVs) and mitigation
AB  - A Novel simulation framework using autonomous drones is used to locate and reduce unauthorized drones in interior environments. The recommended method uses Received Signal Strength Indicator (RSSI) to identify an alien agent drone, which has different signal characteristics than the approved swarm of UAVs. Real-time threat detection is possible with this technology. After detecting the drone, the swarm organizes itself to encircle and contain it for 20 seconds, rendering it immobilized, before the swarm returns to its original formation. This unique solution uses RSSI to quickly identify and mitigate enclosed area concerns. It provides a reliable and effective indoor drone security solution. The simulation results show that the approach works in critical environments such as warehouses, laboratories, and other secure indoor facilities. This study advances unmanned aerial system (UAS) autonomous swarm intelligence and security procedures.
SN  - 3068-5079
PB  - Institute of Central Computation and Knowledge
LA  - English
ER  -
@article{Abro2024Signal,
  author = {Ghulam E Mustafa Abro and Zain Anwar Ali and Ayman M Abdallah},
  title = {Signal Strength-Based Alien Drone Detection and Containment in Indoor UAV Swarm Simulations},
  journal = {ICCK Transactions on Intelligent Systematics},
  year = {2024},
  volume = {1},
  number = {2},
  pages = {69-78},
  doi = {10.62762/TIS.2024.807714},
  url = {https://www.icck.org/article/abs/TIS.2024.807714},
  abstract = {A Novel simulation framework using autonomous drones is used to locate and reduce unauthorized drones in interior environments. The recommended method uses Received Signal Strength Indicator (RSSI) to identify an alien agent drone, which has different signal characteristics than the approved swarm of UAVs. Real-time threat detection is possible with this technology. After detecting the drone, the swarm organizes itself to encircle and contain it for 20 seconds, rendering it immobilized, before the swarm returns to its original formation. This unique solution uses RSSI to quickly identify and mitigate enclosed area concerns. It provides a reliable and effective indoor drone security solution. The simulation results show that the approach works in critical environments such as warehouses, laboratories, and other secure indoor facilities. This study advances unmanned aerial system (UAS) autonomous swarm intelligence and security procedures.},
  keywords = {autonomous drone swarms, RSSI, indoor security, unmanned aerial vehicle (UAVs) and mitigation},
  issn = {3068-5079},
  publisher = {Institute of Central Computation and Knowledge}
}
Publisher's Note
ICCK stays neutral with regard to jurisdictional claims in published maps and institutional affiliations.
Rights and Permissions
Portico